Recommended Free Tools
Some links on this page are affiliate links: if you buy through them we may earn a commission, at no extra cost to you.
Neither predictive nor reactive control is universally better for robot-arm automation. A model-predictive controller can be the stronger choice when the arm must anticipate future motion, constraints, or disturbances and the controller has an accurate-enough model plus enough computation to finish every cycle on time. A feedback-driven reactive controller can be the better engineering fit when current sensor data is sufficient to correct deviations and predictive optimization would add cost, latency, or commissioning work without improving the task.
The practical comparison is not between two standardized robot-arm product categories. “Predictive-controlled” should refer to a defined method, such as model predictive control (MPC), while “reactive” is a broad description of control that responds to measured conditions. The winning design depends on the task, payload, disturbances, timing budget, integration constraints, and validated safety architecture.
As an Amazon Associate I earn from qualifying purchases.
What is predictive control for a robot arm?
Predictive control uses a model of the robot or process to estimate what will happen over a limited future horizon, chooses control inputs by optimizing an objective, applies the first portion of that solution, then repeats the calculation with new measurements. Model predictive control (MPC) is the clearest industrial example.
An MPC controller does not calculate one complete motion plan and then run it blindly. It continually replans. The model may represent joint dynamics, actuator limits, payload effects, contact behavior, or process variables. The optimization can include objectives such as tracking a path, limiting effort, avoiding constraints, or keeping temperatures and forces within bounds. The exact formulation varies by arm and application; MPC is not synonymous with any particular sensor, artificial-intelligence stack, or hardware platform.
#1 Best Overall
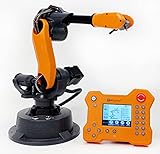
- WLKATA Mirobot Professional Kit. This Professional Kit includes everything in the Education Kit , plus a wireless Bluetooth controller.Part list:Robot arm,Power supply & High-speed USB cable & IDC cable, Pen holding, Micro servo gripper module,Pneumatic set, Multifunctional box,Mirobot Mecha sticker,Handbook,Wireless Bluetooth controller.
- Multiple control methods: computer terminal WLKATA Studio software control, APP mobile phone control, APP mobile phone control, three-dimensional virtual control (V-Rep Ros Matlab),Contains a matching robot controller for better and more comprehensive control
- WLkata Mirobot equipped with laser engraving, writing and drawing, handling and palletizing, mobile app control, etc. Multiple functions, reserved multiple expansion interfaces to support secondary development. Users can develop more application scenarios through software programming and hardware expansion to meet the needs of students of different ages.
- Desktop-level lightweight industrial robotic arm prototype, safe operation, comprehensive functions, freely set actions, add accessories arbitrarily, one arm has unlimited creativity!
- WLKATA is suitable for teaching and training scenarios, color sensor training, multi-fixture coordination training, joint training of six-axis robotic arms and code wheel robotic arms, scene training, painting and calligraphy art training, artificial intelligence voice training, etc.If you have any questions about installation or use, please check the manual or contact us, we will serve you wholeheartedly.
What happens during an MPC cycle?
- Measure the current state. Joint positions, velocities, force data, vision estimates, or other signals are read by the controller.
- Estimate future states. The robot model predicts how candidate inputs would affect the arm over a finite horizon.
- Optimize the inputs. The controller searches for commands that meet the objective and constraints.
- Apply only the immediate command segment. The next command is sent to the arm rather than committing the entire predicted sequence.
- Repeat at the next deadline. New measurements replace old assumptions, allowing the controller to correct prediction error.
This repeated optimization is why MPC can anticipate a constraint or disturbance, but it is also why model quality and computation time are central design requirements. A Control.com technical article dated August 10, 2020 identifies model derivation for complex robots and the number of control variables and resulting computational burden as important challenges. It also described industrial deployment under modeling uncertainty and external disturbance as limited at that time; that is a dated assessment, not a current market-wide measurement.
What does reactive control mean for an industrial arm?
Reactive control is a practical comparison label, not one standardized architecture. It describes a controller that uses current measurements to adapt or correct behavior rather than explicitly optimizing a future trajectory over a prediction horizon. A reactive implementation may adjust velocity, position, force, or a trajectory when sensors report a deviation.
Free tools Windows power users keep installed
One-click scans. No signup required.
Reactive does not mean “uncontrolled,” “open loop,” or “without mathematics.” A feedback loop still requires a plant model or tuned control law in many implementations, and it still needs sensors, calibration, computation, and a defined response time. The distinction is that the controller’s decision is primarily driven by the present measured state and immediate error, rather than by repeated finite-horizon optimization.
How is the robot arm different from its control policy?
The International Federation of Robotics (IFR), citing ISO 8373:2021, defines an industrial robot as an automatically controlled, reprogrammable, multipurpose manipulator programmable in three or more axes for industrial automation. That definition describes the machine, not whether its control policy is predictive or reactive.
The same arm can run a conventional trajectory controller, a sensor-driven correction loop, an MPC layer, or a hybrid arrangement at different levels of its control stack. Surrounding cell controls—safety scanners, interlocks, tooling, vision, conveyors, and PLC logic—also affect performance. Comparing “predictive arms” with “reactive arms” without naming the controller, loop rate, sensors, and cell architecture can produce a misleading conclusion.
What is the difference between predictive and reactive control?
The most useful comparison looks at the task and implementation rather than assigning a universal winner.
Quick wins for a faster PC:
Scan for outdated or missing drivers - takes under a minuteDriver Scan →Repair Windows errors before they cause bigger problemsFix Now →Fix the driver behind crashes, sound loss and screen glitchesFind Drivers →| Decision axis | Predictive/MPC considerations | Reactive/feedback considerations |
|---|---|---|
| Task and disturbances | Useful when future states, constraints, or anticipated disturbances materially affect the result. The benefit depends on how faithfully the model represents the real arm and process. | Often sufficient when current measurements reveal the relevant error quickly and explicit forecasting adds little. |
| Model and computation | Needs a useful model and enough processor capacity to solve the optimization within every control cycle. | Avoids the specific MPC optimization burden, but still needs timely sensing and control computation. |
| Timing and synchronization | Prediction is valuable only if each solution arrives before its deterministic deadline. Missed deadlines can negate the advantage. | Must also meet response-time and multi-axis synchronization requirements; simpler logic does not remove real-time constraints. |
| Adaptation and integration | Can combine sensing with optimization, but model identification, solver configuration, interfaces, and validation can increase integration effort. | Sensor-driven correction can handle observed variation with a more direct loop, while calibration and interface work remain necessary. |
| Safety | No general safety superiority follows from using MPC. The complete cell and its validated safety functions must be assessed. | No general safety superiority follows from reactive control either. Safety depends on the implemented functions and risk assessment. |
This table is a decision framework, not a benchmark. The available evidence does not establish a general speed, accuracy, reliability, or return-on-investment advantage for either approach.
When is predictive or MPC control the better fit?
MPC is most defensible when the future matters enough to justify a model, solver, and tighter engineering process. The following conditions point in that direction.
The arm must respect coupled constraints
Six axes, joint limits, actuator limits, collision margins, force limits, and process windows can interact. A controller that evaluates likely future states can trade off these constraints before the arm reaches them. Whether that works depends on the model, the horizon, and the solver’s ability to return a valid command on schedule.
Disturbances are measurable or predictable
If a conveyor’s motion, changing payload, contact force, or another disturbance can be measured or estimated early enough, a predictive controller may compensate before the error becomes large. If the disturbance is entirely unknown until it occurs and the sensors are slow, the prediction may add little practical value.
Trajectory quality matters across several axes
A coordinated motion can require simultaneous decisions across joints rather than independent corrections. Predictive optimization can express a multi-axis objective, but it must still produce commands compatible with the arm’s low-level servo interface and timing budget.
Rank #2

- 【End-to-End Imitation Learning】Hiwonder SO-ARM101 robot arm is an embodied intelligent hardware platform compatible with the Lerobot open-source framework. It provides developers with streamlined access to shared code, templates, and pre-trained models to explore the latest advancements in AI research.
- 【Dual-Camera Vision System】Equipped with both a gripper-mounted camera and an external camera, the system supports both precise manipulation and environmental awareness for accurate imitation learning.
- 【Hiwonder High-Performance Bus Servos】Featuring 12 high-torque bus servo motors with magnetic feedback, the Hiwonder SO-Arm101 robotic arm delivers smooth, stable motion, eliminating issues like power deficiency and jitter.
- 【Professional Control & Debugging】Integrated with the Hiwonder BusLinker V3.0 debugging board, the system supports servo scanning, real-time status monitoring, and trajectory control. The professional PC software simplifies device calibration and debugging, making it accessible for both researchers and hobbyists.
- 【Open-Source Compatibility】The SO-ARM101 robotic arm is designed to be fully compatible with the LeRobot open-source project. We acknowledge the contributions of the open-source community; all trademarks and copyrights belong to their respective owners.
The team can maintain a useful model
Payload changes, gear friction, compliance, tool offsets, wear, and contact conditions can make a nominal model inaccurate. An MPC project needs a process for identifying, validating, updating, and monitoring that model. A sophisticated controller with a poor model can be less effective than a simpler controller that is well calibrated.
When is reactive feedback the better fit?
Reactive control is often the more proportionate choice when immediate measurements capture the problem and the task does not require explicit anticipation.
Observed variation is the main challenge
If parts arrive with a detectable offset, a vision or force loop can correct the trajectory from the measured deviation. The controller need not forecast a long sequence when the next correction is determined by what the sensor sees now.
The Tool Desk
Outbyte PC Repair FREERepair Windows errors before they cause bigger problemsFix Now →Outbyte Driver Updater FREEFix the driver behind crashes, sound loss and screen glitchesFind Drivers →The task is stable and well bounded
For a repeatable operation with known paths, limited disturbances, and established low-level servo control, adding an optimizer may increase complexity without changing the result that matters to the production process.
Compute and commissioning resources are limited
A reactive loop avoids the specific online optimization workload of MPC. That does not make it free: sensing, calibration, filtering, tuning, diagnostics, and deterministic scheduling still consume engineering time. The advantage is a narrower implementation problem when prediction is not needed.
The controller must fail in a simple, diagnosable way
Direct feedback logic can be easier for a maintenance team to trace when a sensor value, threshold, or trajectory correction causes a fault. This is not a universal property; a poorly designed reactive system can also be difficult to diagnose. Evaluate the actual tools, logs, and support skills available at the site.
How does sensing make a reactive example concrete?
The IFR describes “Sense and Respond” systems in which sensors and vision allow robots to respond to their environment. Its programming example describes a welding workflow: machine vision compares a part with its 3D model, detects deviations, and adapts the robot’s trajectories during the operation.
PC Slower Than It Used to Be?
A free scan shows the junk files, broken settings and background clutter dragging Windows down - then fixes them in one click.Free scan · Windows 10 & 11Outdated Drivers Are Slowing You Down
One free scan finds every outdated or missing driver and matches the right update for your exact hardware.Free scan · exact hardware matchThat example demonstrates sensed adaptation, not proof that reactive control beats MPC. A vision-guided correction can be implemented with different control layers, and the presence of vision does not require artificial intelligence. The engineering questions are which signal is measured, how accurately it is calibrated, how quickly it is available, and which controller consumes it.
The IFR also discusses ROS-Industrial work aimed at improving code reusability while noting concerns about strict real-time requirements, functional safety, and liability in industrial applications. Those concerns apply to integration decisions generally: reusable software does not remove the need to prove timing, safety, and behavior on the selected arm and cell.
Why are deterministic timing and synchronization decisive?
A robot arm cannot benefit from a theoretically better algorithm if that algorithm misses its control deadline. A Control.com white paper on high-performance robot control explains that six-axis arms require coordinated multi-axis motion and deterministic timing; delays or jitter can compromise synchronization and performance.
For an MPC design, the deadline includes state acquisition, filtering and estimation, optimization, validation of the solution, communication, and actuation. The usable prediction horizon is constrained by the cycle time and available compute. A longer horizon may improve anticipation but can increase computation; a shorter horizon may be easier to solve but see less of the future.
Do these 3 things before closing this tab:
1Scan for outdated or missing drivers - takes under a minute2Clear out junk files and repair common Windows errors3Fix the driver behind crashes, sound loss and screen glitchesRank #3
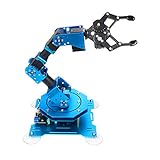
- Spark Your Creativity with Robotic Arm: Hiwonder-xArm1S is a high-quality desktop robot arm capable of remote-control grasping, object transportation, custom actions, graphical programming, and more. It serves as the ideal platform for building and showcasing creative projects and for learning about bionic robotics.
- Intelligent Servo: Hiwonder-xArm1S is equipped with 6 high-precision intelligent serial bus servos that provide position, voltage and temperature feedback. These powerful servos deliver strong torque, enabling the robot arm to grasp objects weighing up to 500g with ease.
- Premium Structure Design: The robot arm is constructed from an exquisite aluminum alloy bracket. The base is fortified with high-torque servos and industrial-grade bearings, guaranteeing exceptional stability.
- Various Control Methods: It supports PC, phone app, mouse, wireless PS2 Wireless Controller, and you can also control the robotic at your fingertips. With these control methods, xArm robotic Arm would bring more methods of play and study, perfect for realizing your innovative programming ideas and coding study.
- Versatile Action Editing: Hiwonder-xArm1S provides various action editing methods through a easy-to-use interface, including PC, app, and offline manual editing. This versatility allows you to easily create a wide range of robot applications.
Reactive control has its own deadline. Sensor latency, image-processing time, communication jitter, and actuator update rates determine how quickly it can correct an error. A feedback loop that responds after the arm has already passed a tight process window is not adequate simply because its algorithm is simple.
Questions to answer before selecting a controller
- What is the required control-cycle period, and what is the worst-case execution time rather than the average?
- Are joint commands synchronized across all axes at the same update boundary?
- What happens when a sensor packet, optimization result, or communication cycle is late?
- Can the system log deadline misses, stale data, solver failures, and command saturation?
- Does the interface expose enough state and command authority for the proposed controller?
How should safety be evaluated?
Neither predictive nor reactive control guarantees safety. Safety must be established for the complete cell through a task-specific risk assessment and validated safety functions. A controller’s ability to anticipate motion is not a substitute for safeguarding, protective stops, speed and separation monitoring, limits, interlocks, or emergency-stop design where those functions are required.
Separate performance control from safety control. An MPC objective that penalizes proximity to an obstacle is not automatically a certified protective function. Likewise, a reactive threshold in application code should not be treated as a safety-rated limit unless the relevant hardware, software, diagnostics, and validation support that claim.
How do you choose between predictive and reactive control?
Use a staged engineering process. Define the task first, then test whether prediction adds measurable value under the real arm, payload, tooling, and disturbances.
- Specify the exact control policy. Write down whether the candidate is MPC, a feed-forward-plus-feedback controller, a vision-triggered correction loop, force control, or another method. Do not compare labels alone.
- Describe the task envelope. Record cycle-time targets, payload and tool changes, part variation, contact events, expected disturbances, allowable tracking error, and constraints that must never be violated.
- Map the sensing path. Identify each sensor, calibration method, update rate, timestamp behavior, filtering, and the point in the control stack where its data enters.
- Set the real-time budget. Define acquisition, computation, communication, and actuation deadlines, including worst-case timing and behavior after a missed deadline.
- Assess model effort. For MPC, determine how the model will be derived, validated, updated, and monitored as payloads, tools, and wear change. Estimate solver complexity with the intended number of variables and constraints.
- Build a representative test. Use the actual arm or a validated digital-twin-to-hardware workflow, the intended payload, realistic part variation, and the disturbances that matter in production.
- Measure the outcomes that decide the project. Capture cycle time, tracking error, constraint violations, deadline misses, recovery behavior, setup time, and maintenance effort. Do not substitute generic claims for task measurements.
- Review integration and safety separately. Document interfaces with the robot controller, PLC, vision, tooling, and supervisory systems. Validate the complete cell’s safety functions through the required process.
- Choose the simplest architecture that meets the specification. If a reactive loop satisfies the measured requirements, MPC may not justify its added complexity. If anticipation materially improves a constrained task and timing is proven, MPC may be warranted.
What should a fair comparison test measure?
A credible comparison uses the same arm, payload, tool, environment, production recipe, and acceptance criteria. It should vary the conditions that motivated the new controller rather than testing only an ideal nominal path.
- Tracking: position, orientation, force, or process-variable error under normal and disturbed conditions.
- Timing: cycle duration, jitter, worst-case computation time, communication latency, and missed deadlines.
- Robustness: behavior across payload changes, part offsets, friction changes, sensor noise, and external disturbances that are realistic for the cell.
- Constraint handling: joint, velocity, force, collision, and process-limit violations, including how the system recovers.
- Operations: calibration time, recipe changes, fault diagnosis, restart procedures, and maintenance skills required.
- Safety evidence: results from the cell’s formal risk and validation process, not an assumption based on the control label.
Report the test conditions with every number. A cycle-time or accuracy result without the arm model, payload, trajectory, sensors, software version, and disturbance scenario cannot establish a general advantage.
Independent reader supportYour contribution helps us test, update, and keep practical guides available for everyone.What are the common implementation mistakes?
Calling every forecast-based feature “MPC”
Feed-forward compensation, trajectory preview, model-based inverse dynamics, and MPC are related but distinct techniques. Name the actual method and identify which layer performs prediction, optimization, and feedback.
Assuming reactive means model-free
Reactive loops can use calibrated kinematics, dynamics, filters, observers, and feed-forward terms. The relevant question is whether the controller explicitly optimizes a future horizon, not whether any model exists.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
Ignoring the low-level controller
An outer-loop optimizer may issue commands to a proprietary servo layer with its own rate limits, interpolation, saturation, and safety behavior. Verify what commands are accepted and how they are time-stamped before promising a control strategy.
Benchmarking only nominal conditions
Prediction is supposed to help when constraints or disturbances matter, while reactive control is often judged by its response to observed variation. Test both under the deviations that occur in the real process.
Confusing adaptation with intelligence
A sensor-triggered trajectory correction can be deterministic and rule-based. Conversely, an optimization-based controller can use sensors without machine learning. Describe the sensing and decision logic precisely.
Rank #4

- Synria Alicia-M is a lightweight 6-axis robotic arm designed for embodied AI research, robotics laboratories, teleoperation, imitation learning, and light industrial automation. It supports advanced manipulation workflows for VLA, ACT, and Diffusion Policy applications.
- With a 750mm working space and 1.5kg continuous effective payload, Alicia-M provides a larger operating range for object handling, testing, teaching, and automation tasks while maintaining a compact desktop-friendly structure.
- Built with precision motion control, Alicia-M offers ±0.1mm repeatability to support reliable task execution, experimental consistency, and long-term robotic operation in research, education, and engineering environments.
- Supports ROS2 teleoperation, gravity compensation, velocity mode, and MIT force control mode, enabling smoother manual guidance, responsive control, and safer interaction during data collection, task demonstration, and robotic learning.
- The full machine weighs approximately 5.1kg and uses DC24V power with CAN communication, making it easier to deploy in labs, classrooms, R&D workstations, and light industrial scenarios. Compatible with open-source robotics workflows and simulation-first control development.
Treating performance control as a safety function
Obstacle penalties, speed commands, and application-level stops may improve behavior but do not by themselves establish a validated protective function. Keep the safety case separate and complete.
Can a robot cell combine predictive and reactive control?
Yes. A common design pattern is to use planning or MPC for the slower, anticipatory layer and feedback loops for fast correction at the servo or process layer. For example, a predictive layer can generate a constrained reference while a reactive loop compensates for measured tracking error, force variation, or small part offsets.
A hybrid design does not automatically avoid the difficulties of either approach. The interfaces must define authority, rates, coordinate frames, saturation behavior, and what happens when the predictive layer is late or invalid. Timing must be analyzed across the combined stack, and safety functions must remain independently validated.
Which approach should you specify in a procurement document?
Specify requirements and evidence instead of demanding a fashionable control label. A useful request should identify the arm and controller interface, payload range, axes, sensors, cycle-time target, allowed tracking error, disturbance scenarios, constraints, logging requirements, and acceptance tests.
Ask suppliers or integrators to explain the control loop and its worst-case timing, model-maintenance process, calibration assumptions, fault handling, commissioning tasks, and safety boundaries. Require demonstrations on representative workpieces and tooling. If the proposal claims better accuracy, speed, or reliability, require the test conditions and measurements supporting that claim.
The final decision is usually straightforward once the task is explicit: choose predictive control when verified anticipation of future states is worth the model and compute it requires; choose reactive feedback when timely response to current measurements meets the process; and combine them when different layers need different time horizons.
Frequently Asked Questions
Can MPC run on a PLC or robot controller?
It can, but feasibility depends on the controller’s available compute, real-time operating behavior, interfaces, and solver implementation. The deciding evidence is a worst-case timing test on the intended hardware, not the fact that an algorithm runs in a simulation.
Does reactive control work without a digital twin?
A reactive loop does not require a full digital twin, although it may still use kinematic models, calibration data, filters, or observers. What matters is that the measured state and control law are sufficient for the required correction.
How often should an MPC model be updated?
There is no universal interval. Update and revalidate the model when payloads, tools, friction, compliance, process conditions, or software change enough to affect prediction quality, and define monitoring that detects degraded behavior between updates.
The Tool Desk
Outbyte PC Repair FREERepair Windows errors before they cause bigger problemsFix Now →Outbyte Driver Updater FREEFix the driver behind crashes, sound loss and screen glitchesFind Drivers →What happens if an MPC solver fails during production?
The cell needs a predefined, validated fallback: for example, holding a safe command, switching to a simpler controller, or stopping under the cell’s protective logic. The fallback must be tested for timing and safety rather than improvised after deployment.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

