The Tool Desk
Outbyte PC Repair FREERepair Windows errors before they cause bigger problemsFix Now →Outbyte Driver Updater FREEScan for outdated or missing drivers - takes under a minuteDriver Scan →Flutter can serve as a cross-platform operator interface for a ROS 2 robot: it can present camera, lidar and telemetry data and provide teleoperation controls. For ROS communication, a practical starting point is the Dart package ros2_client, which connects through rosbridge. Treat multimodal AI—such as voice or vision—as a separate application layer, and treat motion safety as a robot-side responsibility, not a property guaranteed by the app.
What the Flutter and ROS 2 packages provide
Robot-facing widgets with ros2_flutter
The ros2_flutter package listing describes Flutter widgets for ROS 2, including a control-panel pattern with telemetry, camera, lidar and teleoperation. Its API documentation covers connection lifecycle support and widgets for camera and laser-scan data. The package is listed as version 0.2.0 and marked pre-1.0; APIs may change, so verify the current package version, API and platform support before building against it.


As an Amazon Associate I earn from qualifying purchases.
ROS communication with ros2_client
The ros2_client package listing describes a Dart/Flutter client that communicates with ROS 2 through rosbridge. It covers topics, services, actions, parameters and introspection. The package reports 16/16 checks against rosbridge_suite 2.0.7 with ROS 2 Humble and turtlesim. That is a reported result for that specific setup, not a guarantee for every robot, bridge version or ROS 2 distribution.
Recommended Free Tools
In a typical architecture, the Flutter app uses the client to exchange messages through rosbridge, while the robot’s ROS 2 nodes and controllers handle robot-specific behavior. Check that the robot actually exposes the topics, services or actions your app needs, and confirm that its message types and bridge configuration are compatible.
#1 Best Overall
How to plan the interface and communication path
- List the operator’s tasks. Decide which information the app must display and which actions it must request. Camera, laser-scan and telemetry views are supported widget categories documented by
ros2_flutter; the robot’s interface determines the actual topics and message types. - Confirm the ROS 2 and bridge setup. Identify the robot’s ROS 2 distribution, rosbridge version and available interfaces. The
ros2_clientpackage’s reported validation uses Humble, rosbridge_suite 2.0.7 and turtlesim; check your own system rather than assuming that result applies universally. - Choose the communication layer. Use a ROS 2 client such as
ros2_clientfor rosbridge communication, and considerros2_flutterfor its documented UI widgets. Confirm the packages’ current APIs and the target platforms your app must support. - Define behavior for connection changes. Decide how the interface indicates disconnection and recovery, and how it avoids sending obsolete commands after a reconnect. Do not assume queued commands remain safe or useful after an outage.
- Set safety behavior at the robot and controller. Establish command ownership, limits, timeouts, safe-stop behavior and network-failure handling with the robot’s documentation and control software before operating hardware.
What to verify before sending motion commands
Release and disposal behavior
The ros2_flutter API documentation says its teleoperation widgets publish a zero Twist on joystick release and disposal, and repeat the current command while the joystick is held. This can make the UI behavior more explicit, but it does not establish that the robot receives or acts on the stop message in every failure condition.
Stale commands and reconnection
The same API documentation warns that reconnect buffering can deliver stale motion commands after a communication outage. It recommends perishable publishing for motion commands so they are dropped rather than queued, and documents stopping the prior topic when a topic changes. Check that the behavior in the package version you use matches your needs; freshness handling in the app cannot replace robot-side safeguards.
Watchdogs and safe states
A DEV Community article on this topic advises having the robot/ROS 2 side monitor the connection and use a watchdog to move the robot to a safe state when control messages stop. This is advice from that article, not a formal safety standard. Confirm the timeout and safe-state behavior with the robot and controller documentation. A visible stop button or a zero-velocity message by itself does not prove that a system is safe to deploy.
ROS 2 Control documentation for Iron describes hardware-interface concepts, but Iron is end-of-life; consult documentation for the distribution and controller stack actually in use. See ROS 2 Control’s Iron hardware-interface documentation.
Rank #3

- Raspberry Pi 5 & ROS2 Robot Car. MentorPi smart robot car is powered by Raspberry Pi 5, compatible with ROS2, and programmed in Python, making it an ideal platform for AI robot development.
- 360° Omnidirectional Mobility with Mecanum-Wheel Chassis. MentorPi M1 smart robot car is built on a mecanum-wheel chassis, enabling 360° omnidirectional movement. This design provides greater flexibility in various applications and better adaptability to diverse terrains.
- With TOF Lidar & 3D Depth Camera for Advanced AI Capabilities. Supports SLAM mapping, path planning, multi-robot coordination, vision recognition, target tracking, and more, covering a wide range of AI applications.
- High-Performance Hardware & Premium Design. Equipped with closed-loop encoder motors, TOF lidar, 3D depth camera, high-torque servos, and other advanced components to ensure optimal performance and efficiency.
- Autonomous Driving with Deep Learning. Utilizes YOLOv5 model training to enable road sign and traffic light recognition, along with other autonomous driving features, helping users explore and develop autonomous driving technologies.
Where multimodal AI fits
Voice, vision or other AI-driven inputs can be designed as an interaction layer that turns an operator’s intent into a request for the robot. The Flutter package’s documented widgets are for robotics UI and ROS 2 interaction; they are not a complete AI model or a safety-certified control system. Flutter’s AI resources, including Flutter AI Toolkit and GenUI SDK material, are general app-development resources rather than robotics-specific integration instructions.
A 2024 paper, Development of a Human-Robot Interaction Platform for Dual-Arm Robots Based on ROS and Multimodal Artificial Intelligence, describes a ROS-based multimodal interaction platform using voice commands. Its abstract reports positional accuracy under 2 cm for the system described. That result belongs to that particular research setup; it does not demonstrate the accuracy of Flutter interfaces or of robots generally. Read the paper abstract in context.
Rank #4
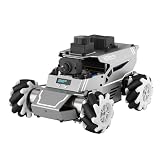
- 【ROS2 & HIGH-PERFORMANCE HARDWARE】ROSOrin runs on the ROS2 framework and is compatible with Jetson and Raspberry Pi. Integrated with LiDAR, 3D Depth Camera, and AI Voice module, this system efficiently processes real-time YOLO series object detection, SLAM mapping, and Large Language Models (LLMs). It provides the reliable "superbrain" and hardware foundation required for Embodied AI and autonomous robotics development.
- 【MULTIMODAL AI & LLM INTEGRATION】ROSOrin supports the integration of leading Large Language Models (including ChatGPT, Gemini, Grok, Llama, and more). By leveraging MLLMs, ROSOrin robot car can achieve semantic understanding and task decomposition. This enables advanced Embodied AI applications such as natural language interaction, complex environment perception, and intelligent path planning for autonomous research.
- 【SLAM & 3D VISION PERCEPTION】ROSOrin AI smart robot car kit supports Gmapping, Hector, and Cartographer SLAM. This robot kit achieves centimeter-level mapping accuracy. Built-in OpenCV and MediaPipe libraries allow for advanced 3D visual tracking, gesture control, and dynamic obstacle avoidance in cluttered environments.
- 【360° OMNIDIRECTIONAL MECANUM CHASSIS】Equipped with high-performance Mecanum wheels(80mm), ROSOrin supports 360° omnidirectional movement, including lateral drifts and complex rotations. This agile chassis allows the robot to navigate through tight spaces and intricate paths with ease.
- 【ALL-IN-ONE ROS2 EDUCATIONAL ROBOT】ROSOrin includes a comprehensive resource library with step-by-step tutorials, open-source code, and AI project examples. From initial build to advanced ROS2 development, it provides everything needed for students and developers to master robot applications.
Compatibility questions to settle for your project
- ROS 2 and bridge: Does the target ROS 2 distribution work with the rosbridge version and client setup you plan to use?
- Platforms: Does the current package support the Flutter platforms you intend to ship on?
- Interfaces and messages: Are the robot’s required sensor and command message types available to the app?
- Connections: What does the app show during disconnect, reconnect and topic changes, and can any queued command be delivered later?
- Motion safety: How are command freshness, joystick release, timeouts, watchdogs and safe stops enforced by the robot-side system?
- AI placement: Does multimodal inference run on the device or through a separate service, and how does its output become a constrained robot request?
These checks matter because the cited package documentation describes useful building blocks, not a complete compatibility matrix or end-to-end safety case for a particular robot.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.




