Do these 3 things before closing this tab:
1Fix the driver behind crashes, sound loss and screen glitches2Clear out junk files and repair common Windows errors3Scan for outdated or missing drivers - takes under a minuteIf an RTK GNSS receiver is not getting corrections, check the physical connection first, then verify port assignment, receiver protocol and baud, and finally follow RTCM data from its source to the rover one hop at a time. These are separate settings and paths: a correct baud rate cannot fix a misassigned port, crossed wiring, or missing correction forwarding.
What should you check first?
Before changing parameters, write down the flight-controller model and firmware, GNSS model and firmware, connector names, and whether each link uses UART or CAN/DroneCAN. Connector labels alone do not establish a matching pinout. The PX4 Guide’s GNSS configuration documentation warns that some ports can be software-compatible but have a different connector pin order.
As an Amazon Associate I earn from qualifying purchases.
- Compare the pinout diagrams. Confirm power, ground, TX, and RX on both devices before connecting them. Do not assume two connectors labelled GPS use the same pin order.
- Confirm the bus and port. A primary serial GPS usually connects to GPS1, GPS&SAFETY, or GPS on a Pixhawk-standard controller; a second receiver may use GPS2. A free UART can also be used if configured. DroneCAN receivers connect to CAN1 or CAN2, not a UART.
- Check the serial wiring. For UART, connect TX on one device to RX on the other, RX to TX, and share ground. Apply power only after verifying voltage and pinout.
For bench access to a u-blox receiver’s UART2, the PX4 Guide’s “u-blox Diagnostics with u-center” page specifies adapter RX to receiver UART2 TX, adapter TX to UART2 RX, and common ground. It identifies the receiver UART pins as 3.3 V; use an adapter with compatible logic levels.
How do port assignment, protocol, and baud fit together?
Think of these as three different questions: which autopilot port is connected? which receiver protocol should the autopilot speak? and at what serial speed should that port communicate? Setting one correctly does not automatically set the others. Parameter names and defaults can change across firmware releases, so check the documentation for the version installed on the vehicle.
#1 Best Overall
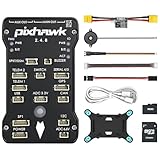
- 𝐒𝐭𝐚𝐛𝐥𝐞 𝐀𝐮𝐭𝐨𝐩𝐢𝐥𝐨𝐭 – Pixhawk2.4.8 can be used as a master controller for fixed-wing, multi-rotor, helicopter, boat, car, etc. By connecting motor, servo, camera, sensor, microcomputer, it enables autopilot or remote driving.
- 𝐒𝐞𝐜𝐨𝐧𝐝𝐚𝐫𝐲 𝐃𝐞𝐯𝐞𝐥𝐨𝐩𝐦𝐞𝐧𝐭 – It is an independent, open source, efficient flight controller, supports rich function modules, and capable hobbyists can carry out secondary development. It is the first choice for autopilot starter, researcher and developer.
- 𝐇𝐢𝐠𝐡-𝐞𝐧𝐝 𝐂𝐨𝐧𝐟𝐢𝐠𝐮𝐫𝐚𝐭𝐢𝐨𝐧 - New layout and technical upgrade base on 3DR PIX. Advanced 32F427 ARM Cortex M4 Core high-performance processor, 32-bit fail-safe co-processor, MPU 6000 3-axis accelerometer.
- 𝐍𝐞𝐰𝐛𝐢𝐞 𝐅𝐫𝐢𝐞𝐧𝐝𝐥𝐲 - We have prepared a quick start guide for new players that will assist you with the basic assembly and calibration of a DIY F450 drone. Please contact us if you need it.
- 𝐐𝐮𝐚𝐥𝐢𝐭𝐲 𝐀𝐬𝐬𝐮𝐫𝐚𝐧𝐜𝐞 - Pass the quality inspection before shipment, free repair or replacement within 3 months if quality problem occurs.
PX4: map the port, then configure the receiver connection
In the PX4 Guide’s mutable main documentation (the GNSS page identifies PX4 v2.0), GPS_1_CONFIG selects the GPS1 port, GPS_1_PROTOCOL selects the receiver protocol, and SER_GPS1_BAUD is Auto for the documented u-blox GPS1 default. A receiver from another supported family needs its matching protocol; the guide gives a Trimble MB-Two at 115200 baud as an example, not a universal setting.
For a secondary receiver, use GPS2 if available or assign a free UART. Set GPS_2_CONFIG to that port; PX4 requires a reboot before dependent settings become available. Then set SER_GPS2_BAUD to match the receiver and its configuration. An unconfigured UART will not become a working GPS port merely because a receiver is plugged into it.
Rank #2
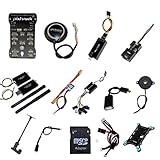
- PIXHAWK intergrated the newest 32 bit chip technology and sensor technology, get rid of the dilemma of having only 8 bit CPU of APM, and CPU occupancy being too high.
- Noted:please use application: Mission Planner to connect and calibrate.
- Pixhawk Flight Controller Kits: all pieces come with connectors installed which makes set up easy.
ArduPilot: use the documented role settings only for the matching setup
For the dual-serial u-blox F9P moving-baseline example in ArduPilot’s “GPS/Compass” documentation, the two GPS serial ports use SERIAL3_PROTOCOL=5 and SERIAL4_PROTOCOL=5; GPS1_TYPE=17 assigns GPS1 the moving-baseline base role and GPS2_TYPE=18 assigns GPS2 the rover role. These are example settings for that arrangement, not defaults for every receiver or vehicle. The same guidance cautions against GPS_AUTO_SWITCH=2 (Blend) for moving-baseline configurations.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
Choose baud for the specific port and traffic
| Documented context | Baud or traffic figure | How to apply it |
|---|---|---|
| PX4 ARK RTK GPS module, as listed in the PX4 Guide’s ARK RTK GPS documentation | UART1 default 921600; UART2 default 230400 | These are defaults for that documented module. Confirm the actual module and receiver configuration. |
| PX4 u-center diagnostic stream over the receiver’s UART2, in the PX4 Guide’s diagnostics documentation | GPS_UBX_BAUD2 defaults to 230400 and must match the USB-to-serial adapter. The guide estimates about 300 bytes per navigation epoch, roughly three times that on an epoch carrying NAV-SAT; it calls 115200 a practical floor at the default 10 Hz rate and says 230400 covers a 25 Hz maximum. | These figures describe that diagnostic message load and update rate, not an RTK baud prescription for every receiver link. |
| PX4 GNSS page’s Trimble MB-Two GPS1 example | 115200 | An example for that receiver and configuration, not a general GPS1 value. |
Do not infer baud from the connector name or copy a value from an unrelated setup. Receiver port, protocol, enabled messages, and update rate all affect the appropriate setting. On PX4, the u-center settings require a reboot according to the diagnostics guide.
Rank #3

- 𝐒𝐭𝐚𝐛𝐥𝐞 𝐀𝐮𝐭𝐨𝐩𝐢𝐥𝐨𝐭 – Pixhawk2.4.8 can be used as a master controller for fixed-wing, multi-rotor, helicopter, boat, car, etc. By connecting motor, servo, camera, sensor, microcomputer, it enables autopilot or remote driving.
- 𝐒𝐞𝐜𝐨𝐧𝐝𝐚𝐫𝐲 𝐃𝐞𝐯𝐞𝐥𝐨𝐩𝐦𝐞𝐧𝐭 – It is an independent, open source, efficient flight controller, supports rich function modules, and capable hobbyists can carry out secondary development. It is the first choice for autopilot starter, researcher and developer.
- 𝐇𝐢𝐠𝐡-𝐞𝐧𝐝 𝐂𝐨𝐧𝐟𝐢𝐠𝐮𝐫𝐚𝐭𝐢𝐨𝐧 - New layout and technical upgrade base on 3DR PIX. Advanced 32F427 ARM Cortex M4 Core high-performance processor, 32-bit fail-safe co-processor, MPU 6000 3-axis accelerometer.
- 𝐍𝐞𝐰𝐛𝐢𝐞 𝐅𝐫𝐢𝐞𝐧𝐝𝐥𝐲 - We have prepared a quick start guide for new players that will assist you with the basic assembly and calibration of a DIY F450 drone. Please contact us if you need it.
- 𝐐𝐮𝐚𝐥𝐢𝐭𝐲 𝐀𝐬𝐬𝐮𝐫𝐚𝐧𝐜𝐞 - Pass the quality inspection before shipment, free repair or replacement within 3 months if quality problem occurs.
Why are corrections not reaching the rover?
RTCM must travel from a correction source—often a fixed base—toward the rover. Identify the source and trace the route through every device and software layer. A base receiving satellite data does not by itself prove that the rover is receiving RTCM.
| Integration route | Expected correction path | What to verify |
|---|---|---|
| PX4 ARK base to rover over DroneCAN | The base connects to QGroundControl; QGroundControl sends RTCM over MAVLink to PX4; PX4 publishes RTCM over DroneCAN; the rover subscribes. | In the PX4 Guide’s ARK RTK GPS setup, check the documented UAVCAN_PUB_RTCM and CANNODE_SUB_RTCM configuration and verify each leg of the route. |
| ArduPilot fixed base through a transparent radio or Wi-Fi link | The fixed base sends RTCM from UART2 through the link to the vehicle’s UART2. | ArduPilot’s RTK correction guidance describes this serial forwarding route. Verify that the link is transparent to the required data and that each endpoint’s TX/RX and port settings match. |
These routes are not interchangeable by assumption. Check the correction source, its output interface, each forwarding mechanism, and the rover’s input. If one hop is absent or configured for a different protocol, changing the rover’s baud alone will not restore the route.
Rank #4
- Wide Compatibility: Supports all major open-source flight control systems, including Ardupilot, PX4, and Betaflight, with official firmware support. INAV will be officially supported from version 8.0, ensuring your flight control system stays up-to-date with the latest technology.
- High-Precision Dual IMU Sensors: Equipped with dual IMU and an integrated compass, providing higher-quality IMU data for navigation tasks such as waypoint flying or hovering, significantly improving the accuracy of navigation and positioning in complex environments.
- O3 FPV Support: Specifically designed compatibility with the O3 Air Unit, supporting HD video transmission and providing a smooth first-person view (FPV) flying experience, meeting professional-grade FPV demands.
- Rich Expansion Interfaces: Features 7 UARTs, 10 PWM outputs, USB Type-C, and support for CAN and I2C buses, allowing connectivity to a variety of external devices such as onboard computers and optical flow laser sensors, offering extensive expandability.
- High-Performance MOSFET Devices ESC: The Electronic Speed Controller uses 40V 165A RDS=1.1mR MOSFET devices, which are key to enhancing ESC performance. An RDS(ON) as low as 1.1mR means minimal internal resistance during current flow, reducing energy loss, increasing efficiency, and resulting in lower heat generation and better load capacity. Especially during long periods of high load, this significantly lowers failure rates and extends lifespan.
Are you configuring fixed-base corrections or moving-baseline heading?
Fixed-base RTK corrections and moving-baseline heading are different jobs. A rover receiving RTCM from a fixed base needs the correction path above. A moving-baseline pair uses a base receiver and a rover receiver to derive heading, with firmware-specific roles and inter-receiver data flow. Do not apply one setup’s mode values to the other firmware.
PX4 ARK RTK GPS moving-baseline modes
| Connection method | Rover configuration | Moving-base configuration |
|---|---|---|
| CAN/DroneCAN | GPS_UBX_MODE=3 and CANNODE_SUB_MBD=1 |
GPS_UBX_MODE=4 and CANNODE_PUB_MBD=1 |
| Direct UART2 | GPS_UBX_MODE=1 |
GPS_UBX_MODE=2 |
The PX4 ARK guide specifies a 5 Hz update rate for these documented moving-base modes. For the direct UART2 path, it says to link the modules’ UART2 ports TX-to-opposite-RX and select the moving-base node with SENS_GNSS_PRIME. The guide states that heading is output only in RTK Fixed, not RTK Float.
Best Value

- POWERFUL MCU & PRECISE SENSORS: STM32F405RGT6 (168MHz, 1MB Flash) with ICM42688-P IMU, DPS310 baro & AT7456E OSD for stable, accurate flight
- VERSATILE CONNECTIVITY: 6 UARTs, 10 PWM outputs, 2 I2C, 3 ADC & SBUS inverter. MicroSD slot for blackbox data logging
- COMPATIBLE FIRMWARE: Supports ArduPilot (MatekF405-Wing, 4.4+) & INAV (MATEKF405SE, 6.0+). USB-C for easy setup
- ROBUST POWER SYSTEM: 9-30V input (3-6S LiPo) with 220A current sensor. 5V/9V/12V/Vx BECs for peripherals & servos
- MULTI-DEVICE SUPPORT: Powers receiver, camera, VTX, GPS & more. 5A Vx BEC (adjustable) for servos; 2A for 5V/9V/12V
ArduPilot dual-serial F9P moving-baseline example
For the ArduPilot dual-serial example described earlier, GPS1 is the moving-baseline base and GPS2 is the rover. If the pair is directly cross-connected through UART2, ArduPilot’s “GPS/Compass” documentation specifies GPS_DRV_OPTIONS=1 to configure RTCMv2 through UART2. Confirm the release-specific behavior and that the receiver roles match before adopting this example.
Could UART2 already be occupied?
Yes. UART2 can be assigned to correction traffic, heading data, or diagnostics, depending on the receiver mode and integration. The PX4 u-center diagnostics mode 7 uses UART2; the PX4 Guide’s listed UART2 RTCM or heading modes include modes 1, 2, and 5. Do not enable the diagnostic mode while expecting the same UART2 to carry one of those other functions. Check the selected mode and the physical wiring, not just the port label.
How can you tell which part of the setup is failing?
Use the receiver and autopilot status to distinguish “no satellite solution” from “corrections absent” and from “corrections arriving but no fixed solution.” On the PX4 ARK RTK GPS guide’s status indicators, blinking blue means corrections have been received and the receiver is at RTK Float; solid blue indicates RTK Fixed. That guide’s moving-baseline heading output requires RTK Fixed.
Work through the fault in order, changing one layer at a time:
- Physical path: check connector pinout, power, common ground, and TX-to-RX direction.
- Port mapping: confirm the autopilot parameter points to the UART or GPS port physically in use, or that a CAN receiver is on the intended bus.
- Receiver protocol and serial speed: confirm the autopilot and receiver agree on protocol and baud for that specific connection.
- Correction route: identify the RTCM source and verify every forwarding hop through QGroundControl/MAVLink, DroneCAN, or a radio/Wi-Fi bridge, as applicable.
- Receiver roles and mode: for heading, verify which unit is base and which is rover and use the parameter set for the installed firmware.
- State and conflicts: check whether corrections arrive and whether the receiver reaches Float or Fixed; then rule out another function occupying UART2.
If the configuration changed but the observed port behavior did not, reboot where the PX4 procedure calls for one, including after secondary GPS mapping and u-center changes. Since the cited PX4 pages follow the mutable main documentation branch and parameter names can shift, verify all settings against the installed firmware and receiver release before flight.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.




