What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
Humanoid robots navigate stairs and uneven ground by combining terrain sensing, foothold and gait planning, and feedback control that adjusts the body as each foot makes or loses contact. That can support impressive demonstrations, but a robot that climbs a particular staircase or obstacle course has not thereby shown it can reliably cross arbitrary rubble.
How does a humanoid robot choose where to step?
Traversal is a repeated control loop, not a single route-planning decision. The robot senses terrain ahead or beneath it, estimates the shape and location of possible footholds, plans foot placement and body movement, then uses feedback to correct its motion through each step. The loop continues as the robot moves, because the ground it encounters may differ from what it estimated before contact.
As an Amazon Associate I earn from qualifying purchases.
Perception and movement planning have to work together. A surface that looks like a usable foothold may be too narrow, steep, or unstable for the robot’s feet and balance strategy. The gait planner must turn the terrain estimate into steps the robot can execute, while the locomotion controller coordinates posture and load transfer as one foot lifts and the other supports the body.
LimX Dynamics describes its CL-1 stair-climbing test as closing a loop among real-time perception, gait planning, locomotion control, hardware, and data streams. That is the company’s account of its demonstration, not an independent comparative benchmark (LimX Dynamics, “LimX Dynamics Unveils Dynamic Testing of Humanoid Robot, Achieving Real-Time Perceptive Stair Climbing and more,” 2023-12-28).
#1 Best Overall
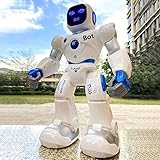
- 【BRILLIANT GIFT IDEA FOR KIDS】It's a big surprise to kids as the robot is up to 15.8 inches in height. With various pioneering ways to play, it can build kids' imagination and creativity. Kids will love this Birthday or Christmas gift!
- 【STEM LEARNING ROBOT】With 10 expressions, 9 flexible joints, and 10 songs, this robot moves more dynamically than typical toys—making playtime more engaging and lifelike. It's a fun way for kids to explore basic programming while building logic, creativity, and coordination!
- 【DIVERSE FUNCTIONS】Gymnastics, storytelling, dance, music, and recording—the Ruko robot enriches childhood with creativity and early artistic exploration. More than just a toy, it’s a fun, engaging friend!
- 【RECHARGEABLE & LONG-LASTING】 Enjoy up to 100 minutes of playtime on a full charge, giving kids plenty of time to play, explore, and have fun without frequent battery changes.
- 【CHARGING REMINDER】For proper charging, please use the original cable included in the package. USB-C to USB-C cables are not supported and will not charge the device. Charge Before Use: No response? Charge for 30 mins first.
What sensors help robots navigate stairs and uneven ground?
There is no single sensor combination established as the standard for humanoid navigation. Different systems can contribute different kinds of information: cameras and depth sensors can help estimate nearby geometry, LiDAR can support scene mapping, and force sensing can reveal what happens when a foot contacts a step.
- Mapping and localization: The sTetro-C staircase-service robot uses a time-of-flight sensor, LiDAR, and an RGB-D RealSense camera for map building and localization. sTetro-C is a reconfigurable service robot, not a humanoid, and its sensor suite is an example of one platform’s design—not a universal recipe. The details are in the Singapore University of Technology and Design repository record “Towards staircase navigation and maintenance using self-reconfigurable service robot,” dated 2025-03-25.
- Contact and step information: Honda’s technical history of the historical P2 humanoid says: “The P2 can use a six-axis force sensor to estimate tread depth to continuously ascend or descend even long flights of stairs without missing its footing.” This is Honda’s description of P2; it does not establish that current humanoids all use the same sensor or approach (Honda, “Honda’s P2 Humanoid Robot: Control Technologies Behind Technical Benchmark for Autonomous Bipedal Walking”).
Sensing alone does not guarantee safe traversal. The robot still has to interpret the measurements, select a feasible foothold, and respond to what it feels during contact.
Rank #2

- 【Humanoid Robot with ESP32】 Powered by ESP32 and 17 intelligent servos, Tonybot smart humanoid robot delivers smooth, dynamic performance. Use the app to easily control it for walking, dancing, kicking, and more. Tonybot can stand up automatically, which is great for playing football and performing gymnastics.
- 【Multimodal Large AI Models】Powered by an AI model module that combines language, voice, and vision models, Tonybot Ultimate Kit unlocks advanced embodied AI functions such as natural conversation and scene understanding. (Ultimate Kit Only)
- 【AI Vision & Voice Interaction】Equipped with an ESP32-S3 vision module and voice interaction module, Tonybot AI robot enables offline face recognition, target tracking, visual line following, voice control, and more. Customize commands and train it to be your AI assistant.
- 【Expandable AI Development with Sensors】 Tonybot robot kit comes with an ultrasonic sensor, IMU sensor, buzzer, and supports modules like dot matrix display, fan, temp/humidity sensors, and WiFi for endless AI-driven development.
- 【3 Programming Options & Comprehensive Tutorials】Tonybot smart AI robot supports Arduino, Python, and Scratch programming, with open-source low-level code and step-by-step tutorials covering everything from beginner learning to advanced humanoid robot development.
How do robots keep their balance while climbing or crossing rough ground?
Balance depends on coordinating foot placement with body posture and the transfer of load between support points. A robot has to manage the motion of its body while a leg swings, then react when the foot lands or when the surface does not behave as expected. Honda’s account of its earlier work describes posture controls for walking on uneven surfaces, resisting pushes, and maintaining stability on stairs and sloping ground (Honda, “Honda’s P2 Humanoid Robot: Control Technologies Behind Technical Benchmark for Autonomous Bipedal Walking”).
Do these 3 things before closing this tab:
1Clear out junk files and repair common Windows errors2Scan for outdated or missing drivers - takes under a minute3Repair Windows errors before they cause bigger problemsResearch projects explore ways to adapt locomotion to perceived terrain and to use more than ordinary foot placement. The Gait-Adaptive Perceptive Humanoid Locomotion project reports experiments in simulation and the real world with a 31-degree-of-freedom, 1.65 m humanoid, including stair ascent and descent and crossing a 46 cm gap. These are project-reported results; the project page excerpt does not establish a publication or version date.
Rank #3
- 6 Fun Robot-Shaped Toys – Includes 6 colorful robots (red, yellow, blue, green, purple, orange) with stretchy pop tube arms & legs for endless bending, twisting, and sticking fun!
- Strong Suction Cup Base – Each robot’s hands and feet have powerful suction cups that securely stick to glass, mirrors, tiles, and smooth surfaces, making them perfect for travel and on-the-go play.
- Sensory & Fidget-Friendly – Helps calm anxiety, improve focus, and relieve stress, making them ideal for autistic kids, ADHD, or anyone who loves fidget toys.
- Perfect Gift & Multi-Use Fun – Great for birthdays, Easter baskets, stocking stuffers, party favors, classroom rewards, or Valentine’s gifts – a hit with kids ages 3-9!
- Safe & Durable – Made from child-safe, non-toxic materials, these stretchy robot toys are BPA-free and designed for long-lasting play.
Stanford’s “Locomotion Beyond Feet” project describes chaining nine whole-body locomotion skills for low-clearance areas, walls, platforms, and steep stairs, with real-world experiments across obstacle sizes and sequences. The project illustrates a different emphasis: the robot can use coordinated whole-body movement rather than treating every obstacle as a conventional walking step. These demonstrations describe research methods and tested sequences, not a general guarantee of performance on any obstacle.
What changes when the terrain is debris rather than stairs?
A stair is usually a sequence of visible, relatively stable surfaces. Debris can be loose, shifting, partly hidden, or low-friction; it may move when the robot touches it. A foothold estimate made before contact can therefore stop being accurate once the robot puts weight on it. This makes perception, foot placement, and feedback control especially interdependent.
Rank #4

- STEAM Learning Made Fun, Building 4C Skills: Yonbo makes learning a blast, the ideal robot for kids aged 4-12 and up! 🚀 It brings STEAM (Science, Tech, Engineering, Art, Math) to life through fun play. 💡With Yonbo, kids develop essential 4C skills—creativity, critical thinking, communication, collaboration—while having a great time. Forget boring lessons or too much screen time, educational robot Yonbo helps kids learn by doing, thinking and imagining. It’s education, but fun and exciting! 🧠✨
- Your Child’s Emotional Robot Companion: This companion robot Yonbo isn’t just a toy – it’s a friend who gets your kid! 😊 With over 100 facial expressions, tones, and movements, emo robot Yonbo reacts to your child’s feelings in real-time. Happy? It dances! Sad? It shows empathy. It’s more than a robot kids toy – it’s a fun, emotional sidekick that kids can bond with, while parents enjoy knowing their child is in good hands. A robot friend, not a gadget! 💖🤖
- Interactive and Immersive Playtime: Goodbye boring playtime! 👋 Interactive robot Yonbo takes fun to a whole new level by recognizing sight, sound and scenes. Yonbo brings stories to life with immersive, interactive fun. 🎧👀 It sings, tells stories and even lets kids embark on imaginary adventures. With sound, action and facial expressions combined, Yonbo creates a whole new world for kids to explore! It’s not just watch a screen – it’s getting involved, and kids’ creativity has no limits! 🌟🎤
- Personalized Play with Customizable AI: Every kid is unique, and so is Yonbo ai robot! 😎 You can totally customize intelligent robot Yonbo’s personality and behavior, based on your child’s interests and even their MBTI personality type. Customizable robot Yonbo takes on any role with style, making every interaction fun and tailored to your child’s imagination. The adventure is always personal! 🦸♀️🐶
- Parental Peace of Mind with Full Control: Parents, you’re in charge – but you can still let your kid enjoy some independence! 😌 With the Yonbo app, you can set the kids robot toy’s personality, monitor interactions, and even get alerts when something’s up. Whether you’re cooking or working, you can control Yonbo robot remotely, ensuring your child is safe and happy. It’s like having a fun, educational robot assistant who also respects your parenting style. 🛠️👨👩👧👦
The available examples do not establish a common debris benchmark or a cross-platform success-rate dataset. Nor do stair-climbing demonstrations establish dependable operation over arbitrary rubble, wet surfaces, or loose material. The claim a demonstration supports depends on the specific platform, terrain, and test conditions that were reported.
Terrain also interacts with the robot’s design. A biped has to manage balance while relying on a limited number of supporting feet; its feet, actuators, body motion, and control strategy constrain which steps it can take. Other platforms use more contact points or combine wheels and legs, changing the terrain strategy rather than proving that one form is universally better.
Best Value
- Remote Control and Hand Gesture Control:This gesture sensing robot not only can be controlled by infrared controller, but also can turn left ,turn right, slide backward, and slide forward according to how your hand gesture commands; Multi function includes auto display and obstacles avoidance as well;The toy robot’s eyes light up with bright blue illuminating LED when it moves;
- Intelligent Programming: This smart robot toy can demonstrating a set of 50 actions inputted by the user.If you switch programming function,this Interactive robot will playback using its moves record feature to repeat the movement one by one as you created like turn left+turn right+walk forward+walk backward+patrol+dance+and many others action mode you selected;
- Premium Material:This Remote Control Robot is made of non-toxic ABS plastic, with flexible multi-joint in shoulder,elbows and thumbs ,and the bottom skating wheels are pretty sturdy to well carry out a various combination of moves;This playful robot really entertain your kids and bring you endless joys;
- Convenient Rechargeable Robot Toy:this RC robot is powered by built-in batteries.Directly connect to USB charging interface like your power bank,plug,computers.Rechargeable way saves your money for batteries and you only recharge the robot about 2 hours, and its playtime is about 60 minutes;
- Ideal Birthday Xmas Gift & Kids Intimate Companion : The infrared control Robot is versatile and vivid can dance,sing,walk,patrol,even can speak.Each robot measures 5.9 x 3.3 x 10.6 inch.
What do published demonstrations actually show?
The projects and platform descriptions below report different kinds of work under different conditions. They are useful evidence of specific capabilities, but there is no controlled head-to-head test in these sources, so they do not support an overall ranking.
| Platform | Locomotion form and approach | Reported terrain or result | Evidence and scope |
|---|---|---|---|
| CL-1 (LimX Dynamics) | Humanoid; company describes a loop linking perception, gait planning, locomotion control, hardware, and data streams. | Dynamic stair ascent, descent of a 15-degree slope, and indoor and outdoor testing as lighting shifted from afternoon to dusk. | Manufacturer-reported demonstration, announced 2023-12-28. It does not establish performance on all stair geometries, wet or loose debris, long-term reliability, or unsupervised deployment. |
| Gait-Adaptive Perceptive Humanoid Locomotion | Humanoid with terrain-adaptive locomotion and real-time under-base terrain reconstruction. | Project reports stair ascent and descent and a 46 cm gap crossing with a 31-DoF, 1.65 m robot. | Research project page reports simulation and real-world experiments; publication or version date not stated on the page excerpt. |
| Locomotion Beyond Feet (Stanford) | Humanoid research approach chaining nine whole-body locomotion skills. | Low-clearance areas, walls, platforms, and steep stairs; real-world experiments across obstacle sizes and sequences. | Research project page; no single general-purpose rubble capability or common success rate is stated. |
| SSR | Humanoid traversal research project focused on surefooted, symmetric locomotion. | Project page reports varied stairs, gaps, high platforms, and outdoor terrain, including continuous open-world traversal of 1.3 km in 40 minutes. | Project-reported traversal; the page excerpt does not establish a publication or version date, and the figure is not an independently verified industry benchmark. |
| sTetro-C | Reconfigurable staircase-service robot, not a humanoid; uses time-of-flight sensing, LiDAR, and an RGB-D RealSense camera for map building and localization. | Staircase navigation and maintenance are the subject of the cited research record. | Singapore University of Technology and Design repository record dated 2025-03-25; sensor details concern this platform, not humanoids generally. |
| Sony six-legged wheel robot | Non-humanoid platform combining wheel travel on even ground with wheel-and-leg movement over height changes such as stairs. | Sony’s 2021-12-14 announcement lists a 30 cm maximum locomotion step and a 20 kg maximum transportable load. | Announced specifications for Sony’s six-legged wheel robot; these values are not comparable measures of humanoid stair performance. |
| ASGUARD II (DFKI) | Non-humanoid mobile platform. | DFKI describes obstacle crossing and stair climbing, and discusses rubble and gravel as rough-terrain demands. | Institutional platform description; comparable quantitative values are not stated in the cited description. |
| Honda P2 | Historical humanoid prototype; Honda describes posture control and six-axis force sensing to estimate stair tread depth. | Honda says P2 could climb and descend stairs, including long flights, and describes work on uneven surfaces and slopes. | Honda technical-history account of a historical prototype, not a specification for current humanoids. |
Because these reports use different robots, obstacles, and test conditions, figures such as gap width, traversal distance, step height, payload, or test duration cannot be combined into a single measure of which system is best. The cited sources do not provide a controlled cross-platform comparison.
How should you judge a stair- or rubble-crossing claim?
Look for the details that connect the claim to a repeatable task rather than treating a dramatic clip as proof of general capability:
The Tool Desk
Outbyte PC Repair FREEClear out junk files and repair common Windows errorsFree Scan →Outbyte Driver Updater FREEFix the driver behind crashes, sound loss and screen glitchesFind Drivers →- Robot type: Is it a bipedal humanoid, a wheeled-legged platform, or a reconfigurable service robot? Their forms imply different ways of handling terrain.
- Terrain and geometry: Does the report specify stair shape, gap size, slope, obstacle sequence, or ground surface? “Uneven terrain” alone says little about difficulty.
- Sensing and adaptation: Does the platform map terrain ahead, use contact or force sensing, and adjust footholds or gait as it moves?
- Test conditions: Is the result a manufacturer announcement or a research demonstration? Are lighting, surface condition, supervision, repetitions, or other relevant conditions reported?
- What was measured: Distances, step heights, payloads, and durations matter only when their definitions and conditions are clear. Do not treat a one-off reported traversal as a success rate or reliability measure.
For the examples covered here, no authoritative cross-platform success-rate statistic establishes how reliably humanoids traverse arbitrary debris. Without a shared test and comparable conditions, the strongest grounded conclusion is about the particular terrain and experiment each source reports.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.




