Free tools Windows power users keep installed
One-click scans. No signup required.
Autonomous-driving developers have not all abandoned modular software for a single end-to-end model. The industry is weighing different ways to connect sensor inputs to driving decisions, and each changes what engineers need to test. Simulation remains useful in either architecture—but for learned end-to-end systems, confidence depends especially on testing the complete input-to-output behavior across varied scenarios, then checking that results hold beyond the simulator.
What does “end-to-end” mean in autonomous driving?
In a traditional modular stack, distinct software stages handle functions such as perception and prediction, motion planning, and control. Pratik Agarwal, GM’s director of onboard autonomy, describes the division this way: “Classical autonomy stacks split the problem into explicit stages: perception and prediction (what’s in the scene and explicit prediction of the scene), a motion plan (where to go), and control (how to actuate).” That is GM’s account of the architecture, not a guarantee that every modular system is easy to inspect or validate.
As an Amazon Associate I earn from qualifying purchases.
An end-to-end model instead learns a mapping from sensor input to a driving trajectory or vehicle command, reducing the traditional explicit separation between those stages. It does not necessarily mean that every vehicle function is one indivisible neural network. NVIDIA’s report describes a related move toward unified models controlling multiple parts of the vehicle stack.
The Tool Desk
Outbyte PC Repair FREEClear out junk files and repair common Windows errorsFree Scan →Outbyte Driver Updater FREEScan for outdated or missing drivers - takes under a minuteDriver Scan →Between those approaches are structured or hybrid designs: learning can span parts of the stack while constraints, interpretable outputs, guardrails, or other structure remain in place. GM calls its proposal “Compound AI.” That is GM’s named approach, not evidence of an industry-wide consensus.
#1 Best Overall
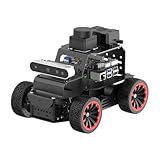
- For Raspberry Pi 5 & ROS2 Robot Car. MentorPi A1 smart AI robot car is powered by Raspberry Pi 5, compatible with ROS2, and programmed in Python, making it an ideal platform for AI robot development.
- High-Performance Hardware. Equipped with Ackerman chassis, closed-loop encoder motors, TOF lidar, depth camera, AI voice interaction box, and other advanced components to ensure optimal performance and efficiency.
- Advanced AI Capabilities. Supports SLAM mapping, path planning, multi-robot coordination, vision recognition, target tracking, and more, covering a wide range of AI applications.
- Autonomous Driving with Deep Learning. Utilizes YOLO model training to enable road sign and traffic light recognition, along with other autonomous driving features, helping users explore and develop autonomous driving technologies.
- Empowered by Large AI Model, Human-Robot Interaction Redefined. MentorPi AI robot car deploys multimodal models with ChatGPT at its core, integrating 3D vision and Al voice interaction box. This synergy enhances its perception, reasoning, and actuation capabilities, enabling advanced embodied AI applications and delivering natural, context-aware human-robot interaction.
Why is end-to-end AI harder to validate?
Explicit module boundaries give developers places to inspect intermediate results and test component behavior. A perception test, for example, can focus on what the system identifies in a scene; a planning test can examine a proposed path. Those checks do not by themselves establish that the complete vehicle system is safe, but they can make faults easier to localize.
When a learned model connects inputs to outputs more directly, features and decisions may be shared across the task. That can make it harder to explain why a particular output occurred or to isolate the source of a failure. GM’s 2026 comparison also characterizes end-to-end approaches as data hungry and opaque, with systematic validation more difficult. These are claims in a company-authored article, not a universal measurement of every implementation.
Rank #2

- OpenMV Smart Robotic AGV Car Kit: Contains AGV car kit for OpenMV cameras
- Auto Tracking Color Balls: Includes color balls for automatic tracking
- Following Lines: Features pre-programmed lines for simple navigation
- Compatible with OpenMV Cam H7 Plus: Works with OpenMV Cam H7 Plus models
- Compatible with OpenMV Cam H7: Works with OpenMV Cam H7 models
The validation question therefore shifts: teams need evidence about the full behavior from sensor input through trajectory or command, not only scores for separate components. A benchmark score or a successful set of ordinary drives cannot cover every unusual interaction, environmental change, or failure mode.
What does simulation add?
Simulation lets developers stage controlled scenarios, vary environmental conditions, send simulated sensor readings to a driving stack, and repeat runs. NVIDIA describes workflows that render sensor data for a system and receive its driving commands in return. Re-simulation can also replay recorded real-world sensor data, allowing teams to examine how a stack responds to the same recorded input.
Rank #3
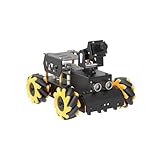
- Raspberry Pi 5 & ROS2 Platform. TurboPi runs on the ROS2 operating system and leverages Python and OpenCV to deliver efficient AI processing and a wide range of robotic applications.
- Multimodal large AI model ChatGPT & Voice Interaction. With an integrated multimodal large AI model and AI voice interaction capabilities, TurboPi supports smart conversations, environment awareness, and flexible task execution for richer human-machine interactions.
- AI Vision & Autonomous Driving. Equipped with a 2-DOF HD camera, TurboPi offers FPV video feedback, object and color recognition, line following, and autonomous driving features—perfect for creative AI projects.
- 360° Omnidirectional Movement. Featuring a robust metal chassis and Mecanum wheels, TurboPi can move in any direction and rotate on the spot, adapting smoothly to various scenarios.
- Comprehensive Code & Learning Resources. We provide full Python source code, diverse experiment examples, and detailed course materials to support your journey in mastering AI and programming while inspiring endless innovation.
These capabilities matter for both modular and end-to-end systems. The architecture affects what engineers can observe and how they diagnose a result; it does not remove the value of repeatable evaluation. Simulation can also help teams deliberately expose a system to unusual scenarios rather than waiting for those situations to occur on public roads.
Use scenarios to ask specific questions
A useful simulation campaign ties each scenario to a behavior or failure mode the team wants to examine. For an end-to-end model, that means looking at the complete input-to-output response, including whether the vehicle command remains appropriate as conditions change. For a modular stack, teams can examine component outputs as well as the integrated result. In either case, repeating a scenario under controlled variations helps distinguish a consistent behavior from a one-off outcome.
Rank #4
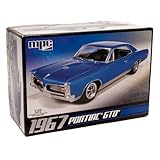
- V8 POWER: The model features a 400 cubic inch V8 engine, reflecting the muscle and power that defined the GTO's reputation.
- DETAILED SUSPENSION & EXHAUST: The kit incorporates separate rear suspension and exhaust detailing, adding to the realism of the model.
- BUCKET SEATS & CONSOLE: The model's interior features bucket seats and a floor shifter with a console, capturing the iconic look and feel of the GTO.
- OPTIONAL SUPERCHARGER: For those seeking more power, the kit offers an optional supercharger, allowing you to customize your model.
- CLEAR & COMPREHENSIVE INSTRUCTIONS: The included instructions are clear and user-friendly, making the kit accessible to modelers of different skill levels, from beginners to experienced hobbyists.
Keep simulator evidence in perspective
A simulated success is evidence about the tested scenario, model, and simulated conditions; it is not, by itself, proof of safety on real roads. Conclusions depend on which scenarios were selected, how faithfully the simulator represents the relevant environment and sensor inputs, and whether observed performance transfers to settings outside the simulator.
The 2017 CARLA paper illustrates why transfer matters. In its experiments, moving to a new town challenged all evaluated approaches, while weather generalization was better. The study also discusses rare-event susceptibility in the end-to-end agents it tested. Those are results for the paper’s models, simulator, and tasks—not a ranking of today’s commercial systems or a claim about every end-to-end model.
Best Value

- Revell Model Kit #14576, Skill Level 4, Contains 74-Parts, Recommended for ages 12 and up
- High-rise four-wheel-drive suspension. Detailed small-block Chevy V-8 engine.
- Old-school spoke “wagon” wheels with oversize off-road tires.
- All-new decal sheet.
- Molded in white and clear with soft black tires. Paint and glue required(not included).
How should teams compare the architectural options?
No single axis settles the choice. The following comparison reflects the general trade-offs described by GM and the limits highlighted by the CARLA study; it is not a measured ranking of current products or deployed systems.
| Question | Modular stack | End-to-end model |
|---|---|---|
| How is driving behavior organized? | Explicit functional stages such as perception and prediction, planning, and control. | Learned mapping from sensor input to a trajectory or vehicle command, with less explicit separation between traditional stages. |
| What can engineers inspect? | Intermediate representations and component boundaries can support component-level inspection and testing. | More integrated learned behavior can be harder to interpret and debug, according to GM’s comparison. |
| What is the data and validation challenge? | Teams can test components as well as the integrated system; component checks do not replace system-level evidence. | GM describes high data needs and harder systematic validation; evaluation must address the full input-to-output behavior. |
| What does the available domain-shift evidence show? | CARLA’s study found that a new town challenged all approaches it evaluated; it does not establish a general modular advantage. | In CARLA’s tested systems, weather generalization was better than town generalization, and the paper discusses rare-event susceptibility for its end-to-end agents. |
| Is there a structured middle path? | Explicit boundaries are central to the traditional modular description. | Hybrid designs can combine learning with constraints, interpretable outputs, or guardrails; GM’s “Compound AI” is one company proposal. |
For a real system, teams should also examine how the architecture handles robustness, availability, scalability, fault tolerance, constraints, and fallback behavior. The Autonomous Safety & Architecture Working Group’s second-edition 2025 report frames these as system-level safety and architecture concerns around an SAE Level 4 Highway Pilot reference use case. It is not an evaluation of one end-to-end model. A credible safety argument has to address the vehicle system and its behavior, not just the model’s benchmark results.
Quick Recap
What should readers take away?
- “End-to-end” describes a learned connection from sensor input to driving trajectory or command; it does not necessarily mean every vehicle system is one neural network.
- Modular boundaries can aid inspection and component testing, while more integrated learned behavior can be harder to interpret and validate.
- Simulation supports repeatable tests and recorded-input replay, but its value depends on scenario coverage, simulator fidelity, and evidence that behavior transfers beyond simulated conditions.
- The sources document an active architectural trade-off, not proof that autonomy developers have converged on one design.
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.




