A Deep Q-Network (DQN) can be trained to control an inverted-pendulum benchmark using raw pixels and a discrete set of actions, without relying on an explicit dynamics model. That is evidence of a promising learning-based control approach—not proof that the system is stable in the formal control-theoretic sense. The distinction matters: benchmark performance alone does not establish safety, robustness, or a stability guarantee.
What the study examines
Bhargavi Ugandhar’s article, “Stabilizing Dynamical Systems with Model-Free Control: A Deep Q-Network Approach,” describes applying a DQN to an inverted pendulum. The controller receives raw pixel data as its state feedback and chooses among discrete actions. The journal abstract presents this as a model-free approach for situations in which detailed system assumptions or prior knowledge may be impractical or unavailable. [C2]
As an Amazon Associate I earn from qualifying purchases.
In this setting, “model-free” means the described controller does not depend on an explicit model of the system’s dynamics. It does not mean the controller has no assumptions, needs no training, or is safe by default. Nor does the description imply that this DQN directly selects continuous-valued actions: the stated action setting is discrete.
What the reported result does—and does not—establish
The abstract reports empirical potential in the benchmark environment. It also explicitly says that benchmark success does not constitute a formal control-theoretic stability guarantee. In practical terms, an observed ability to control the benchmark is not the same as a proof that the closed-loop system will remain stable under defined conditions.
#1 Best Overall

- Total length: 570mm
- Total width: 125mm
- Total height: 382mm (when the pendulum is balanced)
- Pendulum length: 335mm
- Slider effective stroke: 385mm
- Supported: the abstract describes a DQN, raw-pixel feedback, discrete actions, and benchmark-level empirical potential.
- Not established by the abstract: a formal stability theorem, a safety guarantee, physical-robot testing, or robustness to particular disturbances or sensor failures.
The available abstract does not state the network architecture, reward design, training budget, number of trials, benchmark software or version, baselines, or numerical outcomes. There is therefore no supported success percentage or score to report from this record. [C2]
Why empirical control and formal stability are different
Reinforcement learning evaluates a policy through interaction and measured outcomes. A stability guarantee, by contrast, requires a mathematical claim tied to a method and assumptions—for example, a proof that system behavior meets a defined stability property over a stated operating domain. Strong results in a benchmark may motivate further analysis, but they do not supply that proof on their own.
Rank #2

- Total length: 570mm; Total width: 125mm
- Total height: 382mm (when the pendulum is balanced)
- Pendulum length: 335mm
- Slider effective stroke: 385mm
- Angular displacement sensor supply voltage: 3.3-5V
Other data-driven reinforcement-learning work shows that formal analysis can be combined with learning in particular settings. A 2021 Automatica paper available through UCL Discovery describes Lyapunov-based analysis of uniformly ultimate bounded stability using data without a mathematical model, and evaluates off-policy and on-policy algorithms on robotic continuous-control tasks. That is a separate method and study; its analysis cannot be transferred to Ugandhar’s DQN experiment. [C3]
PC Slower Than It Used to Be?
A free scan shows the junk files, broken settings and background clutter dragging Windows down - then fixes them in one click.Free scan · Windows 10 & 11Crashes, No Sound, or Screen Glitches?
Random freezes, missing sound and display glitches usually trace back to one bad driver. Find and replace yours safely.Free scan · under a minuteLikewise, Balázs Varga’s 2022 article, “Deep Q-learning: A robust control approach,” considers deep Q-learning from a robust-control perspective and notes that analytical stability and performance guarantees are seldom available across deep Q-learning applications. It provides broader methodological context, not a result about the inverted-pendulum study. [C4]
Rank #3
- Total length: 570mm
- Total width: 125mm
- Total height: 382mm (when the pendulum is balanced)
- Pendulum length: 335mm
- Slider effective stroke: 385mm
How to assess a model-free control claim
When evaluating a learning-based controller, separate the questions the experiment answers from those that require additional evidence:
- What does the controller observe? Here, the described input is raw pixels rather than explicitly supplied state variables.
- What actions can it take? The described DQN uses a discrete action set, not direct continuous control.
- Does it use an explicit dynamics model? The article’s abstract frames the approach as model-free; that does not itself demonstrate formal robustness or safety.
- What evidence is reported? The available abstract describes benchmark-level empirical potential, not a stability certificate or numerical performance comparison.
- Was it tested beyond the benchmark? The abstract does not establish physical deployment, disturbance testing, sensor-failure testing, or generalization to other systems.
These distinctions help prevent a successful demonstration from being described more broadly than the evidence supports. To judge reproducibility or compare performance, readers would need the full experimental details and reported results, which are not specified in the abstract-level record.
Rank #4
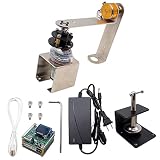
- Product Name: Automatic Rotating Inverted Pendulum
- Overall height (when the pendulum is balanced): 297MM
- Angular displacement sensor voltage: 3.3-5V
- Controller supply voltage: 12V
- Input voltage: AC 100-240V
What the title’s claim should mean
“Advancing dynamical system stability through model-free control and deep Q-networks” is best read as an exploration of how a DQN may control a benchmark when explicit state information or a detailed model is not used. It should not be read as a claim that this study proves dynamical-system stability. The related journal record is dated September 18, 2026; the TechBullion profile that provides the exact-title context was published September 29, 2026. The technical description comes from the journal abstract, while the profile supplies context rather than experimental methods or formal results. [C1] [C2]
Do these 3 things before closing this tab:
1Clear out junk files and repair common Windows errors2Fix the driver behind crashes, sound loss and screen glitches3Repair Windows errors before they cause bigger problemsQuick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.




