If a robot arm is reaching for a cup, differential kinematics answers a precise question: if its joints start moving at these speeds, which way—and how fast—will the gripper move right now? The answer comes from the robot’s Jacobian, a matrix that turns joint velocities into instantaneous end-effector velocity. It depends on the arm’s current pose, so the same motor speeds can produce different tool motion as the arm moves.
What differential kinematics describes
Forward kinematics maps the robot’s joint coordinates to the end effector’s position or configuration. Write that relationship as x = f(θ), where θ is the vector of joint coordinates and x describes the tool’s pose or position.
As an Amazon Associate I earn from qualifying purchases.
Differentiate with respect to time and apply the chain rule:
Outdated Drivers Are Slowing You Down
One free scan finds every outdated or missing driver and matches the right update for your exact hardware.Free scan · exact hardware matchPC Slower Than It Used to Be?
A free scan shows the junk files, broken settings and background clutter dragging Windows down - then fixes them in one click.Free scan · Windows 10 & 11ẋ = J(θ) θ̇
Here, θ̇ is the vector of joint velocities, ẋ is the end-effector velocity, and J(θ) = ∂f/∂θ is the Jacobian. In plain terms, the Jacobian describes how small joint motions combine to make the tool move at the robot’s current configuration. This is a local, instantaneous relationship; it does not by itself describe the entire path the robot will take.
#1 Best Overall
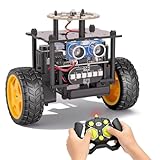
- 【EggTailz Smart Robot Car】This is an educational STEM toys for kids to get experience about electronics assembling and robotics knowledge. DIY assembly and construction will help to cultivate children's concentration and hands-on ability. It is a great combination of challenge and excitement, learning and fun
- 【Multi-functional STEM Toys for Ages 8-13】Equipped with ultrasonic radar allows the car to detect and avoid obstacles in real-time. Headlights for illumination, Taillights for warning, recreating the authentic driving experience. Plus an additional top ring-light, a dazzling light show is about to begin!
- 【Excellent Robot Toys for Children】Featuring advanced self-balancing technology, this 2WD toy car for kids can stays upright and self-corrects its angle. Built-in a rechargeable battery, eco-friendly and convenient—fully charges in 2 hours for 1-4 hours of playtime. Note : Remote control requires 2 AA batteries (Included)
- 【Double Modes, Double the Fun】Auto-Go Mode: the toy car autonomously explores and cruises around the room; Remote Control Mode: you can steer the toy car to forward, backward, turn left, turn right, and 360-degree rotation. Both modes feature radar obstacle avoidance capabilities, offering dual playstyles for twice the enjoyment
- 【Awesome Gift for Kids 8-12】Surprise your child with this awesome robotics kit. Great entertainment away from screens—get kids moving and thinking while reducing their reliance on electronic devices. Perfect educational toy gift for birthdays, Children's Day, Christmas, party, summer camps, back-to-school season, or family fun time
How joint speeds combine to move the tool
Read the Jacobian one column at a time
For a two-joint arm, each Jacobian column gives the tip-velocity contribution from one joint moving at unit rate while the other joint is held still. Multiply each column by that joint’s actual velocity, then add the contributions. The resulting vector is the tool’s instantaneous velocity.
Because the Jacobian depends on the joint configuration, its columns change as the arm changes pose. A motor command that moves the gripper mostly sideways in one pose may move it in a different direction or at a different speed in another pose.
Rank #2

- BUILD, CODE & DRIVE YOUR OWN ROBOT CAR: Turn coding, electronics and engineering into a working programmable robot car you can assemble, program and drive; ideal for weekend family projects, STEM classrooms, coding clubs, robotics lessons and maker challenges
- EXPLORE FPV, LINE TRACKING & OBSTACLE AVOIDANCE: Control the robot with the ELEGOO app or IR remote, view live FPV video through the onboard camera, follow black lines, avoid obstacles with the ultrasonic sensor and explore multiple interactive driving modes
- BEGINNER-FRIENDLY BUILD WITH GUIDED WIRING: Keyed XH2.54 connectors help reduce wiring mistakes, while the illustrated tutorial and example programs guide beginners step by step from chassis assembly and module connection to programming and the first successful run
- GO BEYOND ASSEMBLY WITH CREATIVE CODING: Program with Arduino IDE to explore movement, sensors and control logic, then modify example code to create custom routes, reactions and robotics experiments that develop coding, problem-solving and engineering skills
- COMPLETE RECHARGEABLE STEM ROBOTICS KIT: Includes an ELEGOO UNO R3 controller board, ESP32-WROVER-based camera and Wi-Fi module, line-tracking and ultrasonic sensors, motors, IR remote and a 2000 mAh rechargeable lithium-ion battery; recommended for ages 8+ with adult guidance for first-time builders
Position is not the whole story
For full spatial motion, end-effector velocity is represented as a twist, which includes linear and angular velocity. A space Jacobian or a body Jacobian can map joint rates to that twist. The selected Jacobian and the twist must use the same frame convention; mixing frames makes the velocity calculation inconsistent.
What happens at a robot singularity
A singularity is a configuration where the Jacobian’s rank falls below the maximum rank that robot can attain. At least one end-effector motion direction is then unavailable through joint motion at that instant. For a planar two-link arm, when the links are straightened, the joints’ tip-motion contributions can collapse onto the same line, leaving the tip unable to move instantaneously in another direction.
Rank #3

- Hands-On STEM Robot Learning---This STEM robot kit combines coding, electronics, and robotics into a fun, hands-on learning experience. Powered by an ESP32 controller and guided by 16 story-based tutorials, this robotics kit for kids helps children ages 8–12 and 12–16 build real-world STEM skills. Ideal for robotics for kids, classroom teaching, or at-home learning.
- 3 Programming Languages for All Skill Levels---This coding robot kit supports Scratch, Arduino, and Python, making it suitable for beginners and advanced learners alike. Scratch block coding is perfect for younger kids and first-time coders, while Arduino and Python support deeper learning for teens and tech enthusiasts. A flexible programmable robot designed to grow with students.
- Mobile-Friendly Coding – Learn Anytime, Anywhere---Unlike many traditional robot kits, this robotics kit supports programming on computers, laptops, tablets, and mobile devices like smartphones and iPads. Kids can code directly on mobile devices, making it especially suitable for schools, training centers, and self-learning at home. A practical STEM kit for kids in modern learning environments.
- Build Your Own Robot – Beginner-Friendly DIY---This robot building kit includes HD videos and illustrated step-by-step instructions, allowing kids to assemble the robot independently or with parents. No soldering required. The building process strengthens hands-on skills, patience, and confidence—making it a strong choice among STEM toys for kids and engineering kits for kids. Tutorial path: ACEBOTT Official Website → Resources → WIKI & Assembly Video Note: Batteries not included.
- App & Remote Control for Interactive Learning---Control the robot using the smartphone App (iOS & Android) or the included IR remote. Kids can instantly see how their code affects movement and behavior, reinforcing core coding logic. This robot kit keeps learning engaging while remaining easy to use for beginners.
A singularity is not a sign that the robot is broken. It is a geometric limitation of a particular configuration. Near a singularity, the robot may also need unusually large joint rates to produce motion in certain directions, so a controller must account for joint-speed limits as well as the requested tool motion.
Jacobians can be tall, square, or wide, depending on the number of task-space velocity coordinates and joints. Rank describes how many independent directions the mapping can produce; the shape of the matrix alone does not tell you whether every task-space direction is attainable.
Rank #4

- Intro to Robotics & Circuits: The kit includes motors, PCB microcontroller boards, and wires, by assembling and operating this robotic arm, It offers a fantastic first-time opportunity for children to know how electronic circuits work and control mechanical movement. Combining 3D puzzle with electrical enginnering, it's Fun and entertaining robotic science experiment for kids ages 8-14 and up! Note: 6 AA batteries needed but not included.
- Spark Interest in Engineering: This mechanical arm perfectly combines education with fun. Kids gain hands-on experience in physics & engineering principles while enjoying the thrill of building and play, making learning exciting. It sparks interest in future engineering and science pursuits.
- Challenging & Cool Wood Building Set! With wooden pieces and precise assembly tutorial, this wood building kit offers a satisfyingly complex building experience that enhances problem-solving skills, patience.
- Perfect Gift Idea: Designed for people who love to build and create, this DIY electronics kit for kids makes a gift or basker stuffer for boys and girls, tweens, teens, adults on birthday, christmas, easter, valentine day, also works for students in educational institutions, school science classes like science summer camping toy, or as STEAM game for families. It provides hours of challenging fun and a great sense of accomplishment once completed.
- STEM Project & Fun Toy for All Ages: No solidering required, the robot arm toy comes with all accessories you need to assemble this. Developing a lifelong love for science, the mechanical engineering kit is good for kids, teens, adults, boys and girls 8,9,10,11,12,13,14 years old and up
How inverse velocity kinematics chooses joint rates
In forward differential kinematics, joint rates determine tool velocity. In inverse velocity kinematics, a controller starts with a desired end-effector twist and solves for joint rates that produce it. The Jacobian and desired twist must be expressed in the same frame.
Do these 3 things before closing this tab:
1Repair Windows errors before they cause bigger problems2Fix the driver behind crashes, sound loss and screen glitches3Clear out junk files and repair common Windows errorsWhen the Jacobian is not square or cannot be inverted in the ordinary sense, a pseudoinverse can provide a useful solution:
Best Value

- Discover Engineering with a Real Robotic Arm Kit:This complete engineering kit includes motors, a micro controller, and circuit boards. As kids build and operate this robotic arm kit, they will experience how electronics control movement. It’s the perfect hands-on introduction to robotics and circuits for ages 8-12 and up, blending 3D construction with practical STEM learning
- Full 270° Motion & Multi-Axis Control:Master precise lifting, steering, and full 270° rotation with this interactive robotics for kids ages 8-12. This dynamic design turns physics and mechanical engineering principles into engaging play, sparking creativity and demonstrating how real robotic movement works
- The Perfect STEM Gift for Young Engineers:An ideal gift for birthdays, Christmas, or classroom rewards! This STEM kit appeals to boys, girls, teens, and adults—perfect for solo projects, family STEM nights, or school science programs. It delivers hours of rewarding challenge and a true sense of achievement
- Build & Learn with Challenging Wooden Construction:Assemble with natural wooden parts using clear, step-by-step instructions. This engineering kit for kids age 8-12 offers a satisfying build that sharpens problem-solving, patience, and fine motor skills. It’s a hands-on STEM kit that makes complex concepts tangible and fun
- Interactive STEM Projects for All Ages:From timed competitions to parent-child teamwork, this robotics for kids ages 12-16 turns learning into an adventure. Designed to cultivate future engineers, it’s perfect for home or school use. Inspire a lifelong passion for science and STEM kits for kids age 12-14 and beyond
- Kinematically deficient robot: If the requested twist cannot be achieved exactly, the pseudoinverse gives a least-squares best-achievable twist.
- Redundant robot: If multiple joint-rate vectors can produce the requested twist, the pseudoinverse gives a minimum-norm joint-rate solution.
These are distinct cases: a deficient robot may lack motion directions, while a redundant robot has more joint degrees of freedom than are needed for the task. The pseudoinverse solution does not remove the need to check joint limits, speed limits, or proximity to a singularity.
What a manipulability ellipsoid shows
A manipulability ellipsoid visualizes how readily a robot can move in different directions from its current configuration. Its shape depends on the Jacobian: directions represented by longer axes are available with greater velocity for the chosen joint-velocity scaling, while short axes indicate directions with less capability. At a singularity, the ellipsoid degenerates because at least one direction is lost.
This picture is more informative than a single scalar “dexterity” score, which can hide direction-specific behavior. When comparing poses or robots, consider:
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
- Which task-space directions are attainable, and what is the Jacobian rank?
- How much speed is available in the direction the task requires?
- How close is the configuration to a singularity, or how poorly conditioned is the Jacobian?
- Does the task require linear velocity, angular velocity, or both?
- Is the robot redundant or kinematically deficient for the task?
Linear velocity and angular velocity have different units, so a combined measure involving both requires a deliberate scaling convention. Comparisons are meaningful only when the task, velocity scaling, and convention are consistent.
Where to learn more
Kevin M. Lynch and Frank C. Park’s Modern Robotics, published by Cambridge University Press, covers velocity kinematics and statics in Chapter 5, including Jacobians, singularities, and manipulability. The chapter materials are available at Modern Robotics Chapter 5. The official transcript for Velocity Kinematics and Statics develops the Jacobian relationship and its physical interpretation.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.




