A video surveillance car using an AI-Thinker ESP32-CAM is a small Wi-Fi robot that carries an OV2640 camera. A phone or laptop opens its web page to view a near-real-time JPEG stream and sends movement commands to a motor driver. It is excellent for local-network inspection, robotics learning and temporary observation—not a finished security system.
What the project can—and cannot—do
The car combines a camera, Wi-Fi web server, motor driver, geared motors and a wheeled chassis. Unlike a fixed camera, it can be driven under furniture, around a workshop, through a garage or into another temporarily inaccessible area.
As an Amazon Associate I earn from qualifying purchases.
- Typical capability: local live viewing, forward/reverse/left/right/stop control and optional still-image or microSD functions.
- Not provided automatically: encrypted internet access, dependable cloud recording, night vision, collision avoidance, autonomous patrols or evidence-grade video.
- Use it only where people have given appropriate permission. A basic HTTP camera server should not be used for covert monitoring or exposed directly to the public internet.
System architecture
The ESP32-CAM runs a web server. The OV2640 supplies frames for the stream, while separate GPIO signals operate an H-bridge motor driver.
Phone or laptop browser
          │ Wi‑Fi
   ESP32-CAM web server
      ┌───┴────┐
   OV2640   Motor GPIO
   camera   motor driver
      │          │
 JPEG stream  DC geared motors
Two independent data paths
- Video: the OV2640 captures JPEG frames and the browser receives them over HTTP. This is usually a sequence of images, not H.264 video.
- Control: buttons issue HTTP requests (or, in a more advanced design, WebSocket messages); firmware changes the driver inputs.
Most examples are intended for the same local Wi-Fi network. A local IP address is not an internet address. Access-point mode lets a phone connect directly to the car when no router is available; a VPN is preferable to port forwarding for genuine remote access.
#1 Best Overall
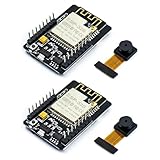
- ESP32CAM is based on ESP32 chip and OV camera module, use low-power dual-core 32-bit CPU, which can be used as an application processor.
- The main frequency is up to 240MHz, and the computing power is up to 600 DMIPS.
- Built-in 520 KB SRAM , external 8MB PSRAM ,support UART/SPI/I2C/PWM/ADC/DAC and other interfaces;Support picture wireless upload, TF card, multiple sleep modes, STA/AP/STA+AP working mode, secondary development.
- It is an ideal solution for IoT applications. The ESP-32CAM comes in a DIP package that plugs directly into the backplane for rapid production.
- ESP-32CAM can be widely used in various IoT applications. Suitable for home smart devices, industrial wireless control, wireless monitoring, QR wireless identification, wireless positioning system signals, etc.
Hardware checklist
| Part | Purpose | Design concern | Alternative or upgrade |
|---|---|---|---|
| AI-Thinker ESP32-CAM with OV2640 | Camera, Wi-Fi and web server | Clones differ in regulator, PSRAM and pin labeling | Raspberry Pi camera computer for higher-quality video |
| USB-to-TTL adapter or ESP32-CAM-MB | Firmware upload | Most boards have no built-in USB | Bundle with a compatible programmer |
| Dual H-bridge driver | Switches motor current and direction | Never drive motors from ESP32 GPIO | TB6612FNG-class MOSFET driver for better efficiency |
| Two or four DC geared motors, wheels and chassis | Propulsion | Four wheels are steadier but draw more current | Two-wheel chassis for a lighter, cheaper build |
| Battery, charger, regulator and switch | Portable power | Motor startup current can reset the camera | Protected rechargeable pack with regulated logic rail |
| Wires, connectors and bulk capacitors | Reliable interconnection | Loose or long motor wiring increases noise | Separate motor and logic harnesses |
Published four-wheel designs commonly use an L298N, four geared motors, rechargeable cells and a charger (example component list). L293D and L298N modules are easy to find, but their bipolar output stages lose more voltage as heat than modern MOSFET drivers.
ESP32-CAM capabilities and GPIO limits
The common AI-Thinker module provides 2.4-GHz 802.11 b/g/n Wi-Fi, Bluetooth capability, OV2640 support, a microSD slot, an onboard flash LED, about 520 KB internal SRAM and external PSRAM on common variants. Its compact footprint is approximately 27 × 40.5 × 4.5 mm according to the AI-Thinker specification.
The OV2640 can capture up to 1600 × 1200, but that does not guarantee smooth streaming. Resolution, JPEG quality, PSRAM, Wi-Fi conditions and power stability determine the usable experience. Board documentation is available from Zephyr and a pinout summary at ESPBoards.
Free tools Windows power users keep installed
One-click scans. No signup required.
Camera signals occupy GPIO0, 5, 18, 19, 21, 22, 23, 25, 26, 27, 32, 34, 35, 36 and 39 on the usual AI-Thinker mapping. GPIO4 is shared with the flash LED and SD interface. Therefore there is no universal list of “free” motor pins: use the exact board definition loaded by your firmware and check boot-strapping and UART conflicts before wiring.
Power design that prevents resets
Battery
 ├── motor-driver motor supply
 └── regulated 5 V (or board-specified input) for ESP32-CAM
       └── common ground with driver
- Do not power motors from the ESP32-CAM 3.3-V pin.
- Use a regulator that tolerates Wi-Fi current peaks, and place bulk capacitance near both the driver and camera supply.
- Connect grounds together at a deliberate point, keep motor wiring short, and separate it from camera and logic wiring where practical.
- A nominal 9-V rectangular battery is not automatically suitable; available current and voltage sag matter.
- Runtime cannot be stated responsibly without measured motor load, battery capacity, regulator efficiency, terrain and camera settings.
Mechanical assembly
- Mount the camera rigidly, with its lens clear of the chassis and wheels; a small vibration-isolating bracket helps.
- Keep the center of gravity low and leave clearance for the camera ribbon and antenna.
- Check wheel alignment and motor polarity before closing the enclosure.
- Protect the board from wheel debris and accidental shorts. A hobby chassis is not weatherproof.
- A pan/tilt servo increases viewing angle but adds weight, current demand and GPIO pressure.
Upload the firmware
- Install Arduino IDE and the ESP32 board package, then select the AI-Thinker ESP32-CAM definition. Menu labels vary by board-package version.
- Disconnect motor power. Wire adapter TX to board RX, adapter RX to board TX, and connect a common ground.
- Connect the adapter’s power according to the particular board and adapter; do not assume every clone has the same regulator.
- Pull GPIO0 to GND, reset or power-cycle the board, and upload. The ESP32-CAM web-server notes document this bootloader requirement.
- Remove GPIO0 from GND and reset again.
- Open the serial monitor, note the assigned IP address, and browse to it from a device on the same network.
Build in three test stages
1. Camera only
- Start with the camera web-server example supplied by the ESP32 Arduino environment or a maintained equivalent.
- Select the correct camera model and enter Wi-Fi credentials.
- Verify still images and streaming with motors disconnected.
- If the stream is unstable, lower frame size and JPEG quality before adding other features.
2. Motors only
- Connect the driver’s logic ground and motor supply separately from the camera rail.
- Test one channel at a time, then the second.
- Confirm forward and reverse direction; swap a motor’s two wires or invert its software logic if needed.
- Make boot and invalid-command states stop both motors.
- Start motors while watching for brownouts or resets.
3. Combined interface
Place the stream and large directional controls on one page. A representative command pattern is /control?go=forward, backward, left, right and stop; these are examples, not a universal API. Publish the exact endpoints implemented by your firmware.
Rank #2
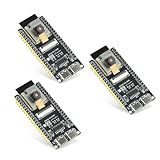
- Dual-core processor: The ESP32 module is based on the powerful ESP32-S3-WROOM N16R8 module and is equipped with a dual-core 32-bit LX7 processor. Its excellent AI computing performance, real-time processing capabilities, and low power consumption make it ideal for image recognition, edge AI, and complex IoT applications
- Integrated 2-megapixel OV3660 camera: Built-in OV3660 camera to capture clear images and stream video in real time. Perfect for smart surveillance, face recognition, and AI-based computer vision projects. It is the preferred solution for DIY makers and professionals to build camera-enabled IoT systems
- Dual Type-C ports for OTG and serial debugging: Designed with two USB Type-C interfaces - one supports USB OTG for host/device functions, and the other provides TTL serial for easy programming and debugging
- Shared antenna: Supports IEEE 802.11b/g/n Wi-Fi (2.4GHz) and Bluetooth 5 (LE and Mesh), using shared antennas to optimize wireless performance. Enhanced 2 Mbps PHY and long-distance communication (Coded PHY) ensure stable multitasking in harsh environments
- Multi-scenario applications: The ESP32 S3 development board maintains high stability even at high temperatures, making it ideal for industrial environments, educational purposes, and AI-driven projects. It is a versatile choice for robots, smart devices, and machine vision in lab or field applications
| Command | Left motor | Right motor |
|---|---|---|
| Forward | Forward | Forward |
| Reverse | Reverse | Reverse |
| Left pivot | Reverse | Forward |
| Right pivot | Forward | Reverse |
| Stop | Off | Off |
Safety and firmware practices
- Stop motors during boot and on malformed commands.
- Use a tested command timeout: if no valid movement command arrives for the chosen interval, call the stop routine.
- Prevent contradictory commands and keep stop independent and easy to press.
- Monitor battery voltage with a correctly designed divider and stop below the selected threshold.
- Keep camera initialization, Wi-Fi, routes, motor functions, timeout handling and optional SD code in separate modules.
- Avoid long blocking delays in request handlers; they make controls lag and interfere with streaming.
Security, privacy and network choices
- Use a private Wi-Fi network and a strong password.
- Do not publish default credentials or expose an unauthenticated HTTP stream through router port forwarding.
- Basic HTTP streaming is normally unencrypted. A VPN is safer for remote access, though more complex.
- Explain whether your build offers live viewing, still capture, SD image storage or actual continuous recording. A stream alone does not create a durable video file.
- Obtain permission before recording people or private spaces.
Troubleshooting
Camera initialization fails
Disconnect motors, reseat the ribbon cable, confirm the AI-Thinker camera selection and board definition, use a stable regulated supply, and inspect serial output. Test the camera-only example before changing motor code.
Upload fails
Ground GPIO0 before reset, verify crossed TX/RX and common ground, select the correct serial port, remove motor power and retry. Remove GPIO0 from ground after flashing.
The Tool Desk
Outbyte Driver Updater FREEScan for outdated or missing drivers - takes under a minuteDriver Scan →Outbyte PC Repair FREEClear out junk files and repair common Windows errorsFree Scan →ESP32 resets when motors start
Suspect voltage sag, shared weak supplies, poor grounding, motor noise or stall current. Separate regulated rails, add bulk capacitance, improve wiring, reduce mechanical friction and choose a driver rated for the motor current.
Stream freezes or controls lag
Reduce frame size and JPEG quality, move closer to the access point, test with motors disconnected, remove blocking delays and keep stream and control routes separate. Browser requests queued behind a stream can make a car feel unresponsive.
The car keeps moving after Wi-Fi loss
This is a serious safety defect. Implement and test the command-timeout stop behavior before driving near people, stairs or fragile equipment.
Rank #3

- 【160° Wide-angle Lens】 This ov2640 AC OV2640 camera module features a 160° viewing angle and 2 megapixels, providing you with an open view. Ideal for esp32 cam, ESP32_camera, esp32-cam, and esp32 camera module projects.
- 【High-Quality Image】 The OmniVision image sensor applies unique sensor technology to improve image quality by reducing or eliminating optical or electronic defects such as fixed-pattern noise, tailing, and floating scatter, obtaining clear and stable color images.
- 【Compact & Low Voltage for ESP32 MCU】 The small size and low operating voltage of this OV2640 camera module provide all required functions for a microcontroller-based UXGA camera and image processor, making it perfect for esp32 camera module applications.
- 【Flexible Output & SCCB/I2C Control】 Controlled via the SCCB bus (compatible with I2C), the OV2640 camera can output 10-bit sampled data at various resolutions in whole frame, sub-sampling, and windowing. It supports JPEG, RGB, and YUV formats for ESP32-CAM.
- 【Full Image Processing Control】 The lens delivers UXGA images up to 15 fps. Users have full control over image quality, data format, and transmission method. All image processing functions including gamma curve, white balance, saturation, chroma, etc., can be programmed through the SCCB interface.
When ESP32-CAM is the right choice
- Choose it for a low-cost, compact local-network prototype, educational robot or moderate-quality browser view.
- Use a separate motor controller when encoders, servos and sensors make camera-board GPIO too restrictive, or when fail-stop behavior must remain independent of streaming.
- Choose a Raspberry Pi-class system when H.264, high-quality recording, HTTPS, authentication, cloud integration, computer vision or autonomous navigation is central.
- Choose a commercial platform for unattended workplace operation, enclosure quality, support and liability requirements.
Useful upgrades
- TB6612FNG-class motor driver for lower voltage loss.
- Protected battery pack, charger and battery-voltage monitor.
- Pan/tilt mount, distance sensor or wheel encoders.
- microSD still-image capture, with retention and file behavior clearly defined.
- Separate MCU for motor control and a VPN for remote access.
Official references include AI-Thinker documentation, Arduino software, Espressif documentation and SunFounder robot-car documentation. A third-party reference price near US$10 for an ESP32-CAM board has been reported, but it is not a universal current retail price and excludes the rest of the car.
Quick wins for a faster PC:
Repair Windows errors before they cause bigger problemsFix Now →Fix the driver behind crashes, sound loss and screen glitchesFind Drivers →Frequently Asked Questions
Is an ESP32-CAM surveillance car suitable for home security?
It is suitable as a supervised local-network prototype. It lacks the encryption, authentication, weather protection, recording reliability and maintenance features expected of a security product.
Does the ESP32-CAM record video automatically?
No. A browser stream, still-image capture and microSD storage are separate features. Continuous, reliable video recording must be implemented and tested explicitly.
Can I control the car from anywhere over the internet?
Not from a local IP alone. Remote operation requires networking beyond the LAN; a VPN is preferable to exposing an unauthenticated HTTP port.
The Bottom Line
The AI-Thinker ESP32-CAM is a strong choice for an inexpensive, educational Wi-Fi camera car. Treat it as a local observation prototype, engineer the power and GPIO details carefully, and move to a Raspberry Pi-class or commercial platform when secure recording, autonomy or unattended reliability matters.
Outdated Drivers Are Slowing You Down
One free scan finds every outdated or missing driver and matches the right update for your exact hardware.Free scan · exact hardware matchWindows Errors? Fix Them Before They Spread
Repair common Windows errors and clear accumulated junk for a smoother, more stable PC - no reinstall needed.Free scan · no reinstallQuick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.




