Crashes, No Sound, or Screen Glitches?
Random freezes, missing sound and display glitches usually trace back to one bad driver. Find and replace yours safely.Free scan · under a minutePC Slower Than It Used to Be?
A free scan shows the junk files, broken settings and background clutter dragging Windows down - then fixes them in one click.Free scan · Windows 10 & 11A UAV motor is not chosen from a headline thrust number. It is chosen from a operating point: a specific motor, propeller, battery voltage, and load that produces a required thrust at a stated current, power, RPM, and temperature. This article walks through how to get from a mission definition to that point, then shows how to read MN4010 data from T-MOTOR without over-reading it.
The title does not give an aircraft mass, rotor count, or mission profile, so no finished configuration can be calculated from it. What follows is the method, with the MN4010 figures used as the manufacturer-published example they are.
As an Amazon Associate I earn from qualifying purchases.
What an operating point actually is
An operating point ties together five things: the motor variant, the propeller, the supply voltage, the thrust produced, and the electrical and thermal state that goes with it. Change any one and the point moves. A throttle percentage on its own does not transfer between setups, because 75% throttle on one battery state and propeller produces a different thrust and current from 75% on another.
A usable operating point therefore records at least:
#1 Best Overall
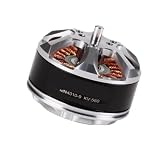
- Fit For MN4010 KV370 Drone
- Stable Power Output Provides smooth and reliable flight performance
- Lightweight Design Helps improve flight efficiency and control
- Easy To Install Supports quick replacement and setup
- Wide Compatibility Suitable for FPV drones and quadcopters Hexacopter or Octocopter
- motor variant (for MN4010, the KV number)
- propeller model and size
- battery voltage used in the test, and the cell count
- thrust, current, input power, and RPM
- efficiency and motor temperature where the source reports them
Step 1: Define the vehicle and mission
NASA’s sizing framework works from design conditions and missions. The NDARC documentation describes the sizing task as determining the dimensions, power, and weight of a rotorcraft that can perform a specified set of design conditions and missions, and it treats each mission as segments whose time, distance, and energy use are evaluated (NASA, NDARC documentation, Input – Vol 3, 2022). Apply the same discipline to a multirotor by recording:
- takeoff mass, including payload and battery
- number of lifting rotors and their positions
- each mission segment (hover, climb, transition, cruise, descent) with its duration and, where relevant, forward speed
- altitude and ambient temperature for each segment
- required reserve
- any degraded or control condition that matters, such as loss of one rotor or a gust-response requirement
If any of these is unknown, the motor point cannot be finalized. Estimate them explicitly and flag the estimate, rather than letting a vendor maximum fill the gap.
Step 2: Find the demanding conditions
Hover balance is the starting point, not the test. A quadrotor can hover with adequate thrust and still lack the climb rate, control authority, or reserve the mission requires. Check each segment separately and keep margin for maneuvers and control.
A NASA motor-sizing study dated 2021 in the NASA Technical Reports Server examined actuator demand on reference vehicles. In the studied vehicles, heave was the most demanding axis when actuator use was translated into current, torque, and power margin, followed by yaw, roll, and pitch. That ranking belongs to those vehicles and that analysis; it does not establish the same order for your aircraft, so calculate the demand for yours.
Rank #2
- Fit For MN4010 KV370 Drone
- Stable Power Output Provides smooth and reliable flight performance
- Lightweight Design Helps improve flight efficiency and control
- Easy To Install Supports quick replacement and setup
- Wide Compatibility Suitable for FPV drones and quadcopters Hexacopter or Octocopter
Step 3: Convert conditions into per-rotor thrust
Split the required total thrust across the active rotors for each condition, then add margin. The arithmetic is simple; the discipline is in running it for every segment and for the degraded case.
Illustration only, using an invented aircraft: a quadrotor with 3.0 kg takeoff mass has a hover requirement of 3,000 g divided across four rotors, or 750 g per rotor. Suppose the control-margin condition calls for 1.3 times hover thrust per rotor, which is 975 g.
Compare that with the MN4010 KV370 example row discussed below. That row gives 820 g at 14.8 V on a 15×5 carbon propeller. The 750 g hover share sits close to it, but the row cannot tell you what throttle produces 750 g on a different battery state. The 975 g control condition is above that row, so you would need to check other rows at higher throttle or a different voltage, or revisit the rotor sizing, before accepting the candidate.
Do these 3 things before closing this tab:
1Scan for outdated or missing drivers - takes under a minute2Repair Windows errors before they cause bigger problems3Fix the driver behind crashes, sound loss and screen glitchesWhat T-MOTOR publishes for the MN4010
T-MOTOR’s MN4010 product page includes manufacturer-published specifications and test tables. The page does not state a publication year, so treat the figures as the current vendor data available to you, with the date unstated.
Rank #3
- Compatibility: Links with multiple power sources and fits standard transmission setups found on diverse multicopter models.
- Installation: Uses a common screw-spacing layout, allowing quick mounting to frame brackets with basic tools.
- Durability: Encased in a sturdy shell with sealed bearing units that ward off sand, dampness, and ordinary flight bumps.
- Performance: Generates uniform force and speed transitions, keeping craft steady as loads vary.
- Suitable For: Serves platforms, freight movers, surveying gear, and leisure aircraft requiring reliable spin action.
Physical data
- Dimensions: Φ44.7 × 30.5 mm
- Stator: 40 mm diameter, 10 mm height
- Shaft: 4 mm
- Mass: 137 g with cables, 112 g without cables
- Battery compatibility as listed: 4–8S LiPo
Continuous ratings by KV variant
The three variants have different continuous limits, so the variant has to match your data exactly.
| Variant | Continuous current | Continuous power | Limit label on the table |
|---|---|---|---|
| MN4010 KV370 | 20 A | 450 W | 180S |
| MN4010 KV475 | 30 A | 540 W | 180S |
| MN4010 KV580 | 31 A | 575 W | 180S |
The “180S” label is the manufacturer’s own designation for the duration to which these figures apply. The page does not explain it in the material available here, so do not treat these numbers as indefinitely sustainable. Confirm what the label means in the current product documentation before designing around it.
The page’s maximum-thrust claim
The page describes a maximum thrust of 2.2 kg and recommends the T-MOTOR P15×5 propeller. This is a vendor claim. The test conditions behind it should be read from the test tables, and it is not an aircraft-level sizing result.
Step 4: Read a complete test row
A row is only meaningful with its voltage and propeller attached. The example row from the MN4010 KV370 table is:
Rank #4
- Compatibility: Links with multiple power sources and fits standard transmission setups found on diverse multicopter models.
- Installation: Uses a common screw-spacing layout, allowing quick mounting to frame brackets with basic tools.
- Durability: Encased in a sturdy shell with sealed bearing units that ward off sand, dampness, and ordinary flight bumps.
- Performance: Generates uniform force and speed transitions, keeping craft steady as loads vary.
- Suitable For: Serves platforms, freight movers, surveying gear, and leisure aircraft requiring reliable spin action.
| Field | Value |
|---|---|
| Motor | MN4010 KV370 |
| Propeller | T-MOTOR 15×5 CF |
| Voltage | 14.8 V |
| Throttle | 75% |
| Current | 5.1 A |
| Input power | 75.48 W |
| Thrust | 820 g |
| RPM | 3,800 |
| Efficiency (grams of thrust per watt) | 10.86 g/W |
Three checks confirm you are reading it correctly. Voltage times current gives 14.8 V × 5.1 A = 75.48 W, which matches the input power. Thrust divided by input power gives 820 g ÷ 75.48 W = 10.86 g/W, so the efficiency figure is grams of thrust per watt, not a dimensionless propulsion efficiency. And 14.8 V is the nominal voltage of a 4S pack; a 4S LiPo charged to 4.2 V per cell reads about 16.8 V, so this row does not cover full-charge operation.
Motor temperature appears only in some rows. The page states its temperature condition as motor surface temperature at 100% throttle after 10 minutes. Apply that only to rows where it is reported, and do not read it as in-flight cooling performance.
Step 5: Check limits and margins
A motor point that meets thrust can still fail electrically or thermally. Check each of the following against your installed hardware:
Free tools Windows power users keep installed
One-click scans. No signup required.
- Continuous current and power. Compare the operating current and power from your mission segments with the variant’s continuous rating. Keep headroom for battery sag and temperature rise.
- Battery under load. Use voltage under load, not open-circuit voltage, to determine the operating point. Confirm the pack’s continuous discharge rating and cell count fall within the motor’s 4–8S listing.
- ESC rating. The ESC must handle the peak and continuous current at the voltage used, with its own margin.
- Wiring and connectors. Check gauge and connector ratings for the peak current in each segment.
- Motor cooling. Confirm the airflow and mounting provide adequate cooling for the mission duration, not just the bench test.
- Propeller clearance. Confirm the 15×5 or other chosen propeller clears the frame, arms, and landing gear at full deflection.
- Reserve. Confirm that battery capacity covers the mission plus the required reserve at the worst-case segment current.
Step 6: Validate the installed combination
Bench-test the selected motor, propeller, ESC, and battery with instrumentation that records thrust, voltage, current, RPM, and temperature together. Then confirm the aircraft-level requirement with staged flight tests: hover first, then climb, control response, and the degraded case, with clear abort limits at each stage.
Best Value
- Compatibility: Links with multiple power sources and fits standard transmission setups found on diverse multicopter models.
- Installation: Uses a common screw-spacing layout, allowing quick mounting to frame brackets with basic tools.
- Durability: Encased in a sturdy shell with sealed bearing units that ward off sand, dampness, and ordinary flight bumps.
- Performance: Generates uniform force and speed transitions, keeping craft steady as loads vary.
- Suitable For: Serves platforms, freight movers, surveying gear, and leisure aircraft requiring reliable spin action.
The vendor’s static table is a bench reference. It is not flight-test evidence for your aircraft.
Step 7: Iterate across the mission
If a candidate meets peak thrust but draws too much current, runs hot, or shortens endurance below reserve, change one variable at a time. The usual levers are the propeller, the voltage (cell count), the motor variant, rotor size, or the mission assumptions. NASA’s NDARC approach emphasizes sizing followed by off-design mission and point-condition analysis, which is why a candidate that passes one condition is re-checked across the others.
Comparing two candidate setups
When comparing two real combinations, keep the same comparison axes and attach the variant, voltage, propeller, and test condition to every number:
- thrust at the required condition
- current and input power at the actual battery voltage
- efficiency at that point, in g/W where the vendor uses that measure
- RPM and propeller suitability
- motor temperature and cooling, with the test condition named
- headroom to the applicable current and power limits
- control and reserve margin
A comparison that drops the voltage or propeller from one side is not a comparison.
Quick Recap
“
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.




