Quick wins for a faster PC:
Scan for outdated or missing drivers - takes under a minuteDriver Scan →Repair Windows errors before they cause bigger problemsFix Now →Fix the driver behind crashes, sound loss and screen glitchesFind Drivers →Making an industrial robot safer to work alongside starts with the complete application, not the robot’s marketing label. Assess the robot, end-effector, workpiece, nearby equipment, layout, software, tasks, people and environment together; address hazards during normal and non-routine work; install and validate suitable safeguards; maintain them; and train each worker before assignment. A robot described as “collaborative” can still crush, trap, strike or project material if its tool, payload, speed, sequence or surrounding cell creates unacceptable risk.
What “safe to work alongside” actually means
ISO describes collaborative robotics as an application or system in which automated equipment shares a workspace with people. That definition concerns the way the system is designed and used, not a permanent property of a robot arm. The same arm may be acceptable in one task and hazardous in another because the end-effector, workpiece, reach, speed, force, fixtures, access routes or neighboring machines differ.
As an Amazon Associate I earn from qualifying purchases.
Safety therefore has to be demonstrated for a defined task and operating mode. A risk assessment should answer who can enter the robot’s working envelope, why they enter, what can move, what can be released, how motion is stopped, how a restart is authorized and what happens when something fails. It should cover production, setup, programming, testing, adjustment, cleaning, maintenance, repair, recovery from faults and foreseeable misuse.
ISO’s safety working-group guidance captures the central principle. Carole Franklin, Secretary of ISO/TC 299/WG 3, says: “The fact is,” explains Carole Franklin, Secretary of ISO/TC 299/WG 3, “when robots work alongside humans, we have to be very careful that the application does not put a human in danger.”
#1 Best Overall
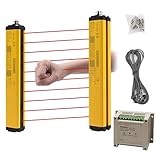
- ROBUST HOUSING- Thick aluminum alloy shell, stable performance, powerful output , and reliable safety.
- ACCURATE MONITORING- The detection is accurate and the response speed is as fast as 10ms. Meets International Electrotechnical Society IEC61496-1/2 standard, designed according to European standards, and has passed CE certification.
- SECURITY PROTECTION- This safety light curtain emits infrared light, resulting in a protective screens. When the light curtain is blocked, the device emits a blackout signal and control potentially dangerous machinery and equipment stops working, or an alarm signal, control and alarm devices to achieve the purpose of security.
- WIDE APPLICATIONS- Reliably protect people or objects in paper machinery, leather machinery, woodworking machinery, injection molding machine, forging machine, punching machine tools, security monitoring etc. Mainly used for the pipeline restricted area, bending machine, injection molding machine,stereo garage and and other dangerous equipment
- High Performance- Built-in amplifier, using modulated light source, programming synchronous scanning mode, strong resistance to external interference, easy to install
Start with the application, not the robot label
Set the system boundary
Include every item that can create or change a hazardous movement:
- Robot, controller, drives, software, programmed paths and operating modes.
- End-effector, gripper, cutter, welder, dispenser, magnet, vacuum system and stored energy.
- Workpiece, fixtures, pallets, tooling, sharp edges, hot surfaces and parts that can detach.
- Conveyors, presses, machine tools, sensors, turntables, guarding and adjacent robot cells.
- Floor plan, restricted and safeguarded spaces, access gates, visibility, lighting, noise and environmental conditions.
- Human duties, including loading, unloading, inspection, teaching, cleaning, jam clearing, fault recovery and maintenance.
Consider interactions between cells. OSHA notes that restricted spaces can overlap: a person working on one system may be struck by another robot or workpiece, trapped between systems or peripheral equipment, or hit by a projectile.
Identify everyone who can be exposed
List operators, setters, programmers, integrators, maintenance and repair staff, quality inspectors, cleaners, contractors, supervisors and visitors. Account for language, experience, reach, visibility, personal protective equipment and the possibility that someone enters for a reason not anticipated by the production sequence.
Perform and document a lifecycle risk assessment
OSHA recommends assessing risk at design, manufacturing, integration, operation and maintenance stages. The assessment is a living engineering record, not a one-time sign-off. Document the task, hazard, person exposed, initiating event, existing control, residual risk, responsible owner and verification evidence.
- Describe intended operation. Map each automatic cycle, manual interaction, loading and unloading action, inspection point and restart condition.
- Analyze start-up and programming. Include teaching, jogging, program selection, parameter changes, testing at reduced speed, and recovery after an interrupted cycle.
- Analyze non-routine work. Examine setup, adjustment, cleaning, jam clearing, scheduled and unscheduled maintenance, troubleshooting, repair and emergency intervention.
- Identify hazards and initiating events. Consider unexpected start, incorrect program, sensor failure, communication loss, power restoration, dropped loads, tool breakage, fixture failure and human error.
- Evaluate the environment and installation. Check floor strength, clearances, access routes, lighting, temperature, dust, liquids, electromagnetic conditions and nearby equipment.
- Estimate risk for each exposure. Consider severity of harm, likelihood, frequency and duration of exposure, and the ability to avoid or limit the hazard.
- Select risk-reduction measures. Prefer inherently safer design where practical, then safeguarding and complementary administrative measures.
- Verify the result. Test normal and abnormal scenarios, record measurements and confirm that safeguards achieve the intended safety function.
- Reassess after change. Repeat the review when the task, program, tool, workpiece, layout, process, safeguard or maintenance method changes.
OSHA’s Technical Manual specifically calls for attention to programmed tasks, environmental conditions, location and installation, possible worker errors, malfunctions, emergencies, worker duties and application-specific hazards. The assessment should be approved by the employer and retained with the cell’s technical and operating documentation.
Look beyond collision hazards
A person does not have to collide directly with the robot arm to be injured. OSHA identifies several hazard patterns that should be considered separately.
Rank #2

- ROBUST HOUSING- Thick aluminum alloy shell, stable performance, powerful output , and reliable safety.
- ACCURATE MONITORING- The detection is accurate and the response speed is as fast as 10ms. Built-in amplifier, using modulated light source, programming synchronous scanning mode, strong resistance to external interference, easy to install
- SECURITY PROTECTION- This safety light curtain emits infrared light, resulting in a protective screens. When the light curtain is blocked, the device emits a blackout signal and control potentially dangerous machinery and equipment stops working, or an alarm signal, control and alarm devices to achieve the purpose of security.
- Self-check function: When the safety screen protector fails, ensure that the wrong signal is not sent to the controlled electrical appliances.
- High Performance- Built-in amplifier, using modulated light source, programming synchronous scanning mode, strong resistance to external interference, easy to install
| Hazard pattern | How it can occur | Questions to answer |
|---|---|---|
| Struck by moving robot or equipment | An arm, carriage, turntable or neighboring machine enters a person’s space unexpectedly. | What motion can reach the person, and what validated stop or separation function prevents it? |
| Trapped or crushed | A worker is pinned between the robot and a fixture, wall, conveyor, floor or another machine. | Are pinch points eliminated or guarded? Can a person escape? Is restart prevented while anyone is inside? |
| Projectile or ejected material | A gripper loses a part, a tool breaks, a fastener is expelled or process material is thrown. | What containment, shielding, retention and exclusion distance are needed? |
| Hazardous process energy | Welding, laser cutting, machining, hot surfaces, sharp tools, pressure, electricity or chemicals add risk. | Which process-specific controls, personal protection and isolation procedures apply? |
| Unexpected restart | Power returns, a fault clears, a mode changes or a remote command starts motion. | What reset, restart and energy-isolation conditions must be satisfied? |
ISO’s ISO 10218-1:2025 page notes that robot applications can create additional hazards such as welding, laser cutting and machining. Those hazards must be addressed in application design rather than assumed to be covered by the robot standard alone.
Choose safeguards for the actual interaction
ISO identifies four collaborative techniques. They are design options, not guarantees. Select one or a combination only after analyzing whether people and robots truly need to share a task or merely a workspace, whether contact is expected, how proximity or contact is detected, and what the tool and workpiece can do.
| Technique | How it works | When it may fit | Important limits |
|---|---|---|---|
| Safety-rated monitored stop | The robot reaches a validated safe stop before or while a person occupies the shared workspace. | Loading, inspection or intervention when motion can be stopped and held safely. | The stop, monitoring, reset and restart sequence must be validated; residual hazards from tooling or gravity remain. |
| Hand guiding | A worker guides motion through a designed safety control arrangement, normally using a dedicated enabling or guiding device. | Teaching, positioning or low-volume tasks requiring direct human control. | Guiding controls, speed, release behavior and the payload must be assessed; ordinary physical contact with the arm is not a substitute for a safety function. |
| Speed-and-separation monitoring (SSM) | A protective presence-sensing system detects intrusion and causes the application to stop; operation resumes only after the area is clear and the restart conditions are met. | Processes where people approach intermittently and the robot can maintain a calculated protective distance. | Sensor placement, response time, stopping distance, blind spots and the complete envelope must be validated. An industrial safety light curtain may be appropriate in some designs, but a generic curtain is not suitable for every cell. |
| Power-and-force limiting (PFL) | Contact is expected or permitted only where force and pressure are limited to assessed thresholds. | Tasks requiring close proximity or intentional contact with a suitably designed robot and tool. | Tool, workpiece, geometry, speed, force, pressure and vulnerable body regions all matter. A low nominal robot speed or “cobot” label does not establish safe contact. |
OSHA notes that SSM and PFL can be combined: the application may run faster when no worker is nearby and slow as a person approaches. That behavior still requires application-specific risk controls, validated safety functions and a defined response to faults.
Design the cell so safeguards work in practice
Use physical separation where contact is unnecessary
Fences, fixed guards, interlocked gates, barriers, tunnels and controlled access are often the most direct solution when people do not need to share the task. Design them to prevent reaching around, over or under the barrier. Account for the robot’s full reach, tool orientation, payload swing, dropped-part trajectory and neighboring equipment.
Protect access and restart
Access devices should produce the intended safety response, withstand the environment and prevent automatic restart after a person leaves. Locate reset controls where the operator can see the safeguarded space, or use a validated alternative that prevents someone from remaining inside unseen. A reset should not itself initiate hazardous motion.
The Tool Desk
Outbyte PC Repair FREERepair Windows errors before they cause bigger problemsFix Now →Outbyte Driver Updater FREEFix the driver behind crashes, sound loss and screen glitchesFind Drivers →Keep emergency functions distinct
Emergency-stop devices are for stopping hazardous motion in an emergency; they do not replace risk reduction, guarding or safe isolation. Define how emergency stops, protective stops, mode selectors, enabling devices and energy-isolation procedures interact, and test each state transition.
Rank #3

- Cutting-Edge Technology - Utilizing infrared scanning detection technology, this safety light curtain sensor system embodies the most recent innovations in automatic control products, ensuring exceptional performance.
- Fast Response & Anti-Interference: Experience quick response times and robust anti-interference capabilities with this light curtain sensor switch, ensuring reliable safety in diverse industrial environments.
- Robust Aluminum Alloy Construction: Built to last, this safety grating security device is crafted from high-quality aluminum alloy, offering longevity and dependable protection for forging machines, automation equipment, and more.
- Versatile Application: From shearing machines to industrial robots, this sensor is designed for a variety of machinery. It's ideal for use in production lines, packaging equipment, and solid garages, providing a versatile safety solution.
- Enhanced Efficiency: Featuring low energy consumption and fast response times, this sensor not only saves energy but also enhances operational efficiency, contributing to overall productivity in industrial settings.
Control the end-effector and workpiece
Assess gripping force, vacuum loss, sharp edges, heat, stored pressure, cutting points and the consequences of a dropped or ejected part. Add retention, guarding, containment or a safer tool where necessary. A robot arm that limits force can still carry a sharp, hot or heavy object capable of serious injury.
Write procedures for non-routine work
Programming, setup, testing, adjustment, maintenance and repair can place a worker inside the working envelope when unintended movement is possible. Treat these activities as designed operating modes, not informal exceptions.
- Define the permitted mode. Specify who may select manual, teach, setup or maintenance mode and what speed and motion limits apply.
- Control enabling devices. Require deliberate, continuous action where appropriate; define what happens when the device is released or squeezed.
- Use point-of-operation visibility. Position controls so the person commanding motion can see the robot and anyone who could be exposed.
- Isolate hazardous energy. Use the site’s lockout/tagout or equivalent isolation procedure for electrical, pneumatic, hydraulic, mechanical, thermal and stored energy.
- Prevent remote commands. Disable or control external starts, automatic program selection and networked commands during intervention.
- Plan fault recovery. Document how to clear jams, retrieve dropped parts and verify that no person or tool remains in the cell before reset.
- Set hand-back criteria. Require inspection, guard replacement, test-cycle results and an authorized return to automatic operation.
Do not rely on a worker’s judgment to stay clear of an energized robot. Procedures should make the safe action the easiest action and specify when production must remain stopped.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
Train people and verify competence before assignment
OSHA says people who assemble, install, program, integrate, operate, maintain or repair robot systems should receive adequate safety training and demonstrate competency before assignment. Training should match the person’s actual duties rather than consist only of a generic online briefing.
Operator competency
- Recognize the cell boundary, hazards, protective devices and permitted operating modes.
- Perform start-up, loading, unloading, inspection, stop, reset and restart steps in the written sequence.
- Respond correctly to alarms, protective stops, dropped parts and abnormal sounds without entering an unsafe space.
- Know when to stop work and call an authorized programmer, maintenance worker or supervisor.
Programmer, integrator and maintainer competency
- Understand the robot program, safety-rated functions, speed limits, tool data, payload, modes and interlocks.
- Apply energy isolation, test procedures, enabling controls and controlled re-entry.
- Recognize how a software, tool, fixture, layout or parameter change alters the risk assessment.
- Verify protective devices after adjustment or repair and document the result.
Use observation, practical demonstrations and task-specific checks to confirm competence. Retrain after a change, incident, near miss, long absence or evidence that a worker cannot perform the procedure reliably.
Validate, maintain and monitor the safeguards
OSHA advises that selected safeguards and risk-reduction measures be reviewed, approved and fully implemented. Reliability and timely maintenance matter, and safeguards must not introduce new hazards or block necessary worker visibility.
Rank #4

- ROBUST HOUSING- Thick aluminum alloy shell, stable performance, powerful output , and reliable safety. Beam Pitch 40mm, Beams 26, Protection Height 1000mm, Total Height 1080mm
- ACCURATE MONITORING- The detection is accurate and the response speed is as fast as 10ms. Meets International Electrotechnical Society IEC61496-1/2 standard, designed according to European standards, and has passed CE certification.
- SECURITY PROTECTION- This safety light curtain emits infrared light, resulting in a protective screens. When the light curtain is blocked, the device emits a blackout signal and control potentially dangerous machinery and equipment stops working, or an alarm signal, control and alarm devices to achieve the purpose of security.
- WIDE APPLICATIONS- Reliably protect people or objects in paper machinery, leather machinery, woodworking machinery, injection molding machine, forging machine, punching machine tools, security monitoring etc. Mainly used for the pipeline restricted area, bending machine, injection molding machine,stereo garage and and other dangerous equipment
- High Performance- Built-in amplifier, using modulated light source, programming synchronous scanning mode, strong resistance to external interference, easy to install
- Test every safety function. Check gates, switches, scanners, light curtains, monitored stops, enabling devices, emergency stops, mode selection and restart prevention.
- Test worst-case stopping. Use the maximum relevant speed, payload, reach, temperature and wear condition when determining whether separation and stopping distances remain adequate.
- Check diagnostic behavior. Confirm that a failed sensor, broken cable, lost communication or inconsistent signal produces the intended safe response.
- Inspect on a schedule. Look for damaged guards, misaligned sensors, defeated interlocks, degraded cables, changed fixtures and unauthorized software or tool changes.
- Record maintenance and proof tests. Include date, person, method, result, defect, corrective action and release authorization.
- Control bypasses. A temporary defeat requires authorization, compensating measures, a defined duration and documented restoration.
Maintenance is part of the safety design. A safeguard that works only when perfectly aligned, clean and fully understood is not reliable enough unless the site can maintain those conditions and detect deterioration.
Know which standards and laws apply
United States
OSHA’s robotics overview states that there are currently no specific OSHA standards for the robotics industry. That statement does not remove an employer’s duty to comply with applicable OSHA requirements. OSHA’s Technical Manual explains that robot applications must comply with applicable OSHA regulations and that consensus standards are guidance from their originating organizations, not OSHA regulations.
Use OSHA requirements that apply to the workplace and process, then use relevant consensus standards to engineer and verify the robot system. A company should obtain competent legal and safety advice for its jurisdiction and industry rather than treating a consensus standard or a supplier declaration as a complete compliance determination.
International and ISO context
ISO 10218-1:2025 is the third edition of the robot-level standard for industrial robots as machines, published in February 2025. ISO states that integration and robot applications are covered by ISO 10218-2:2025. The distinction matters: a compliant robot component does not by itself establish that the integrated cell is safe.
ISO/TS 15066:2016 supplements ISO 10218-1 and ISO 10218-2 for collaborative industrial robot systems and their work environment. ISO says the document was reviewed and confirmed in 2022, remains current and is marked “to be revised.” Do not present the 2011 editions mentioned in older OSHA Technical Manual references as the newest ISO editions.
PC Slower Than It Used to Be?
A free scan shows the junk files, broken settings and background clutter dragging Windows down - then fixes them in one click.Free scan · Windows 10 & 11Crashes, No Sound, or Screen Glitches?
Random freezes, missing sound and display glitches usually trace back to one bad driver. Find and replace yours safely.Free scan · under a minuteFor Europe, EU-OSHA’s OSHwiki reports that revised EN ISO 10218 editions were published in 2025 and incorporated collaborative-robot requirements previously set out in ISO/TS 15066. Confirm harmonization, presumption-of-conformity rules and legal status for the specific market before making a compliance claim.
Best Value
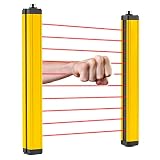
- [Fast Reaction] - The light curtain sensor responds as fast as 0.01 seconds. And the detection distance between transmitter and receiver can be up to 5m. NOTICE: the beam pitch of all types of the safety light curtains is 40mm, which is suitable for wrist or body detection.
- [Security Guard] - This safety grating is mainly used to protect personal safety and reduce work-related injuries. According to research, 90% of work-related injuries are due to lack of safety protection.
- [Stable Output] - It does not need a synchronization line since the power supply can be supplied separately. And it can resist electromagnetic interference and has stable output.
- [Wide Application] - It is applicable to machine tool operation area, production line, automatic welding line, automatic equipment, cutting and pressing equipment, etc. In addition, it has a high protection grade (IP65) and can be suitable for various working environments.
- [Good Quality] - The safety light curtain has a high-brightness indicator light, which makes its working state easy to identify. And the surface is treated with high-quality baking varnish, which makes it waterproof, oil-proof and well sealed.
Reassess whenever the application changes
Risk can change without replacing the robot. Reopen the assessment before approving any of the following:
- A new end-effector, gripper, tool, payload or workpiece.
- A faster speed, altered path, new program, changed force limit or different operating mode.
- Relocation of the robot, fence, sensor, reset station, conveyor or adjacent cell.
- A process change such as welding, machining, laser work, heating, dispensing or pressure.
- A new maintenance, cleaning, inspection or jam-clearing method.
- Replacement or adjustment of a guard, scanner, light curtain, interlock or safety controller.
- An incident, near miss, unexpected stop, nuisance trip or repeated bypass.
Keep the approved assessment, drawings, safety-function calculations, validation records, procedures, training records and change history together. This documentation lets the next reviewer understand not only what control was selected, but why it was adequate for the task and how it is kept effective.
What current evidence says about collaborative-robot use
EU-OSHA’s 2024 European Working Conditions Survey reported that 10% of respondents in the industry sector said they used cobots at work. That figure describes the respondents and sector covered by that survey; it is not a global adoption rate and does not indicate that the reported systems were safe or unsafe.
Recommended Free Tools
ISO’s collaborative-robot guidance also records a philosophical question from Roberta Nelson Shea, Convenor of the ISO Industrial Robot Safety Working Group (ISO/TC 299/WG 3): “When working on the standards for safety of industrial robots (ISO 10218-1 and ISO 10218-2), a philosophical discussion arose. If an application will not hurt and injure a human, why not allow contact?” The practical answer is that contact can be considered only when the complete application demonstrates acceptable force, pressure, geometry, energy and failure behavior. Otherwise, prevent contact through separation and safeguarding.
A practical decision sequence for a new or modified robot cell
- Describe the job. Write what the robot, tool, workpiece and people do in every operating mode.
- Map exposure. Draw the robot’s reach, tool envelope, dropped-part trajectory, pinch points and overlap with nearby equipment.
- List hazards by task. Include normal production, setup, programming, cleaning, maintenance, faults and emergencies.
- Reduce inherent risk. Remove unnecessary energy, sharp edges, access and manual interventions before adding administrative controls.
- Select safeguards. Decide whether separation, monitored stop, hand guiding, SSM, PFL or a combination fits the assessed interaction.
- Specify safety functions. Define sensors, logic, stopping behavior, reset, restart, diagnostics, access and energy isolation.
- Validate under realistic conditions. Test maximum payload, speed, reach, foreseeable errors, failed components and neighboring equipment.
- Train and authorize. Assign only people who have demonstrated competence for their specific duties.
- Operate a change process. Reassess and revalidate whenever the application or its maintenance conditions change.
The result should be a controlled work system in which the robot, people, software, equipment and procedures remain safe together throughout the system’s life.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

