Mars rover mobility is a coordinated system, not just a set of wheels. Raised metal grousers bite into soil and rock, six independently driven wheels share propulsion, and the rocker-bogie suspension keeps the wheels in contact while limiting body tilt. Cameras and visual-odometry software then measure slip and actual progress so drivers can choose safer routes. Perseverance’s wheel changes, made after Curiosity experienced damage from sharp rocks, show how flight experience feeds directly into rover hardware.
What gives a Mars rover traction?
A rover moves when its wheels can push backward against the ground without losing too much contact. On Mars, that ground may be loose sand, compacted soil, bedrock, or a jumble of sharp stones. The wheel system has to work across all of them while carrying a heavy vehicle in low gravity.
As an Amazon Associate I earn from qualifying purchases.
Perseverance uses six aluminum wheels with machined, raised ridges called grousers. Each wheel is 20.7 inches (about 52.5 to 52.6 centimeters, depending on the NASA page’s rounding) in diameter and has 48 gently curved grousers. The ridges increase the wheel’s grip on both soft sand and hard rock. They aid traction; they do not eliminate wheel slip.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
Every wheel has its own drive motor. Independent drive lets the rover distribute propulsion rather than relying on one axle. A wheel that encounters a different patch of sand, a rock, or a depression can turn at the speed needed for the vehicle’s motion. Steering and drive commands are coordinated with the suspension so the rover can keep moving without asking one wheel to carry all the load.
#1 Best Overall
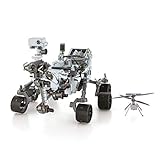
- HOBBY MODEL KIT – Unassembled model packed in an envelope with easy to follow instructions. Ideal for ages 14 and up.
- NO GLUE OR SOLDER NEEDED – Parts can be easily clipped from the metal sheets. Tweezers are the recommended tool for bending and twisting the connection tabs.
- MARS ROVER PERSEVERANCE & INGENUITY HELICOPTER – 4.5 Sheet Model with a challenging difficulty level. Assembled Size: Rover: 4.92 L x 3.54 W x 2.95 H inches. Helicopter: 1.02 L x 1.30 W x 0.79 H inches. 1:30 Scale.
- FROM STEEL SHEETS TO 3D – Pop out the pieces and connect using tabs and holes. Includes illustrated instructions.
- HIGHLY DETAILED ETCHED MODEL – Display your 3D model once completed - collect and build them all.
How the rocker-bogie suspension keeps wheels on the ground
The six wheels are connected by a rocker-bogie suspension. The linked arms let the wheels move relative to the rover body as the vehicle crosses uneven ground. NASA describes the arrangement as maintaining relatively even wheel loading and reducing body tilt. A NASA educational explanation puts the practical result plainly: “The rocker-bogie design of the ‘legs’ allows the rover to keep all of its wheels on the ground, even on uneven terrain.” NASA, “Learn About Me: Curiosity”.
Perseverance’s component description says the rover can cross an obstacle or depression up to approximately one wheel’s size—20.7 inches (52.5 centimeters). That is a design capability, not a guarantee that every obstacle of that height is passable. The actual result depends on the obstacle’s shape, edge sharpness, soil strength, wheel position, vehicle attitude, and the route leading to it.
Why even loading matters
If one wheel drops into a hole or climbs a rock, the suspension transfers motion through the rocker and bogie links so the other wheels remain engaged. Keeping several wheels loaded gives the drive motors more opportunities to produce useful force. It also reduces sudden changes in the rover body’s angle, which matters for antennas, cameras, instruments, and the rover’s ability to maintain a planned heading.
Free tools Windows power users keep installed
One-click scans. No signup required.
Rank #2

- Mars Exploration Made Easy: GalaxyRVR, compatible with Arduino Uno R3, recreates the experience of real Mars rovers. Inspired by NASA’s rocker-bogie suspension system, it easily travels over rocks, sand, and grass—delivering true off-road capability beyond ordinary robot cars. Powered by solar charging and equipped with real-time FPV, smart obstacle avoidance, and remote control, it brings an immersive Martian adventure right to you. Start with easy controls, then advance to Arduino programming or Scratch block coding. Perfect for students, educators, and DIY enthusiasts
- Tough and Terrain-Ready: GalaxyRVR, crafted from sturdy aluminum alloy and featuring a rocker-bogie system like real Mars rovers, is designed for outdoor exploration and effortlessly tackles diverse terrains such as sand, rocks, grass, and mud pits for seamless adventure
- Solar-Powered and FPV: GalaxyRVR comes equipped with a solar panel, enabling solar charging. Its ESP32 CAM, paired with an app, offers remote control and a real-time FPV experience, bringing exploration to your fingertips
- Intelligent Obstacle Avoidance and Enhanced Lighting: GalaxyRVR is fitted with ultrasonic and infrared sensors, ensuring effective obstacle avoidance. Enhanced by RGB light strips and ESP32 LED lighting, it not only brings vibrancy but also confidently illuminates its path, making exploration in the dark possible
- Beginner-Friendly with Comprehensive Support: The GalaxyRVR kit is designed for easy assembly, allowing users to get started quickly without frustration. It comes with detailed online tutorials and step-by-step video lessons, ensuring a smooth learning curve. Coupled with an active community forum and responsive technical support, even novices can confidently bring this project to life
Suspension articulation is not unlimited climbing ability
The suspension can accommodate uneven ground, but it cannot make a weak surface strong or provide grip where the soil collapses. A wheel may spin in loose sand even while the suspension is functioning normally. Likewise, a tall rock with a sharp edge can threaten the wheel skin even when the vehicle can physically articulate around it.
Why Perseverance changed the wheel design used on Curiosity
Curiosity’s wheels are about 20 inches (50.8 centimeters) in diameter and use 24 pointed, chevron-pattern grousers. Perseverance’s wheels are slightly taller and narrower, use twice as many tread elements, and have a wheel skin twice as thick according to the Jet Propulsion Laboratory press kit. The newer design responded to the way Curiosity’s pointed tread interacted with sharp, pointy rocks.
| Feature | Curiosity | Perseverance |
|---|---|---|
| Wheel diameter | 20 inches (50.8 cm) | 20.7 inches (about 52.5–52.6 cm; NASA pages round the conversion differently) |
| Tread count and shape | 24 pointed chevron-pattern grousers | 48 gently curved grousers |
| Wheel skin | Thinner than Perseverance’s; exact thickness not stated in the cited material | Twice as thick as Curiosity’s, according to the JPL press kit |
| Drive arrangement | Six-wheel rover with individually controlled wheels | Six independently driven wheels |
| Wheel width | Not stated in the cited material | Not stated in the cited material |
| Design lesson | Pointed tread was more vulnerable to damage from sharp rocks | Curved, more numerous grousers and thicker skin were tested to improve durability over rocks and sand |
NASA’s design discussion reports that testing showed the Perseverance changes improved damage tolerance and performance over rocks and sand. That does not mean the new wheels are damage-proof or that they deliver a universal performance increase on every surface. It means the hardware was selected to address a documented weakness while retaining the traction needed for loose and hard terrain.
Rank #3

- IGNITE SPACE EXPLORATION PASSION: Dive into the world of Martian engineering with the Perseverance Mars Rover, an immersive NASA-inspired STEM toy. Assemble and operate a real working Mars rover powered by a powerful motor, equipped with a movable robotic arm, strong grip, and powerful torque, offering the excitement of Martian exploration up close.
- UNVEIL STEM WONDERS: Unbox the future of learning with the Perseverance Mars Rover kit, containing 71 pieces and a 60-page educational and instructions booklet. Aimed at kids aged 8 and above, this kit is more than just a toy—it's a gateway to hands-on STEM education, fostering curiosity and understanding in robotics, mobility systems, electrical connections, and transmission systems, among other disciplines.
- MASTER SPACE MISSION CONTROL: Embark on a journey of discovery as you assemble and control the Perseverance Mars Rover model. With its DC motor capable of driving uphill and crossing uneven surfaces, children simulate Martian exploration missions, learning about the intricacies of mobility systems and experiencing the excitement of space missions on the Red Planet.
- EMPOWER FUTURE INNOVATORS WITH STEM EDUCATION: Inspire the next generation of scientists and engineers with the Perseverance Mars Rover. Through interactive play, children not only gain valuable insights into robotics, engineering, and space exploration but also develop essential skills like hand-eye coordination and concentration, laying the foundation for future STEM careers and innovations.
- BOND THROUGH COSMIC ADVENTURES: Bring families and friends together with the Perseverance Mars Rover kit, fostering teamwork and collaboration as they tackle assembly challenges and simulate Martian exploration missions. Spark lively discussions about space exploration and science, creating lasting memories filled with learning and fun.
How rovers drive on sand without simply spinning in place
Grousers engage the surface
On sand, the raised grousers press into the grains and provide a mechanical surface against which the wheel can push. The wheel’s contact patch and the pressure carried by the suspension determine how much force can be transmitted before the sand shears and the wheel slips. A curved grouser profile gives Perseverance many engagement points around the wheel rather than concentrating loads at a few sharp tips.
Six motors share the work
Because each wheel is driven independently, the rover can continue making progress when the ground under one wheel is weaker than the ground under another. The system does not turn every wheel at an identical speed merely because they are on the same vehicle; wheel motion is managed as part of the overall drive command. If the wheels rotate faster than the rover is actually advancing, that difference is slip rather than useful travel.
Visual odometry checks the distance actually traveled
Curiosity uses visual odometry to compare terrain features seen in successive images. The software estimates how far the rover moved between drive steps and identifies wheel slip, including on steep slopes and sandy ground. Fine-grained terrain may lack distinctive rocks or other features, so Curiosity can use its own tracks as visual features for the software to follow. This prevents wheel rotation alone from overstating progress.
Rank #4

- Gift Envelope Includes - Unassembled Model Easy to Follow Instructions
- From Steel Sheets to Museum Quality 3D Model
- Assembled Size 3.65x3.35x2.35 inches
- No Glue or Solder Needed
- Ages 14+
In practice, a drive is therefore a feedback problem: command wheel motion, observe the terrain and rover motion, estimate slip, and adjust the route or next drive segment. The measurement does not create traction; it tells the team when the planned motion is not matching the real motion.
How Mars rovers cross rocks and depressions
Approaching an obstacle
A rover is not expected to attack every rock head-on. Route planning considers the approach angle, the height and shape of the obstacle, the wheel positions, and the body tilt that would result. A rounded, isolated rock may be easier to cross than a lower rock with a sharp edge or a loose pile that can shift under load.
Do these 3 things before closing this tab:
1Scan for outdated or missing drivers - takes under a minute2Repair Windows errors before they cause bigger problems3Fix the driver behind crashes, sound loss and screen glitchesClimbing onto the rock
As a front wheel rises, the rocker-bogie links let the wheel articulate upward while the rest of the vehicle remains supported by the other wheels. The drive motor supplies torque through the grousers, and the suspension helps keep contact as the wheel moves over the surface. The system’s ability to cross an obstacle roughly the size of a wheel describes its geometry and articulation; it is not a promise that every wheel-sized obstacle can be crossed safely.
Best Value

- Feed a passion for science and technology – Kids can learn more about the challenges of space exploration with this LEGO Technic NASA Mars Rover Perseverance (42158) building toy set
- Conduct a test flight – This advanced building kit for kids ages 10 and up includes a buildable toy version of NASA’s Ingenuity helicopter, which accompanied the Perseverance Rover and was used to test powered flight on Mars
- AR brings the mission to life – The accompanying augmented reality app experience lets kids dive into the details of the rover and its mission
- Explore the functions – Features 360° steering, movable arms and fully articulated suspension that lets the vehicle travel across uneven surfaces, plus buildable scientific instruments
- A gift for kids who love engineering – This Mars Perseverance Rover NASA toy makes a great gift idea for kids with a passion for space exploration, technology or science projects
Descending and avoiding high-centering
After the front wheels pass the crest, the middle and rear wheels encounter the same feature. The suspension must keep enough wheels loaded to prevent the rover from rocking excessively or becoming supported on the body rather than the wheels. Drivers also avoid sequences of obstacles that create an unfavorable combination of pitch, roll, and wheel unloading even when each individual rock appears manageable.
Independent reader supportYour contribution helps us test, update, and keep practical guides available for everyone.What “steep” means: tilt tolerance versus a usable route
NASA states that Perseverance is designed to withstand a 45-degree tilt in any direction without tipping. NASA also says rover drivers avoid terrain expected to tilt the rover more than 30 degrees. These statements describe different things:
- 45 degrees: a stated stability-design tolerance—the rover is designed not to tip at that tilt under the described condition.
- 30 degrees: an operating practice used in route planning to avoid terrain that would produce a more extreme attitude.
Neither number is a universal maximum climbing angle. A slope’s drivability depends on direction, surface texture, wheel loading, loose material, rocks, and the rover’s current path. A rover may face a lower-angle sandy slope that is harder to climb than a firmer, steeper-looking rock surface, because available traction and slip differ. Conversely, a slope within a structural tolerance can still be rejected if the predicted wheel slip or body attitude is unacceptable.
Why tilt is monitored conservatively
Excessive tilt can unload wheels, increase the chance of sliding, complicate communication or pointing, and place instruments at attitudes outside their preferred operating range. Conservative route planning leaves margin for errors in terrain models and for changes in the surface once a wheel begins to dig in.
How a rover drive is planned and checked
- Map the candidate route. Images and terrain models are examined for rocks, depressions, sand, and slopes. The team looks for a path that keeps predicted tilt and wheel loading within acceptable limits.
- Choose a drive segment. Commands specify the intended distance, heading, steering, and wheel motion. The segment is kept bounded so the team can assess what happened before committing to the next one.
- Apply propulsion through all six wheels. Independent wheel motors and the rocker-bogie suspension work together as the rover encounters different surfaces under each wheel.
- Measure actual motion. Visual odometry compares images of terrain features and, when necessary on feature-poor ground, the rover’s tracks. The result estimates travel and slip rather than assuming wheel rotation equals distance.
- Re-plan when the surface disagrees with the model. Unexpected slip, a new obstacle, or a larger-than-expected tilt can lead to a shorter drive, a different heading, or a route around the hazard.
Common misconceptions and failure modes
- “The treads prevent slipping.” Grousers improve purchase, but loose sand can still shear beneath a wheel and produce slip.
- “A wheel-sized rock is always passable.” The published obstacle figure describes the rover’s component capability, not every combination of rock shape, soil, approach angle, and wheel placement.
- “Forty-five degrees is the climb limit.” It is a stated no-tip design tolerance, while drivers avoid routes expected to exceed 30 degrees of tilt. Neither is a universal climb-angle rating.
- “Perseverance cannot damage its wheels.” Its curved grousers and thicker skin improve damage tolerance over Curiosity’s design, but sharp rocks remain a hazard.
- “Wheel rotation proves distance traveled.” Slip can make rotation overstate progress, which is why visual odometry checks the rover’s movement against visible features.
What the wheel evolution teaches
Curiosity and Perseverance show that rover mobility is an iterative engineering system. The basic architecture—six driven wheels, grousers, and rocker-bogie suspension—provides traction and articulation. Operations add another layer: imaging, slip estimation, and conservative route selection. Perseverance’s wheel geometry and thicker skin incorporate lessons from Curiosity’s interaction with sharp rocks, but the newer rover still depends on careful driving rather than on a wheel design that makes terrain risk disappear.
Try the principle with a small rover experiment
NASA’s “Gaining Traction on Mars” STEM activity asks participants to design and test wheel prototypes on simulated Martian terrain. A useful experiment compares smooth wheels with wheels carrying different grouser shapes, then records distance traveled and visible slip on sand, gravel, and a firm surface. The exercise illustrates the same distinction used by mission teams: a wheel can rotate successfully while the vehicle makes little forward progress.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.
Quick wins for a faster PC:
Clear out junk files and repair common Windows errorsFree Scan →Scan for outdated or missing drivers - takes under a minuteDriver Scan →Repair Windows errors before they cause bigger problemsFix Now →
