Freedom251 › 3D Scanning Software
3DUNDERWORLD-SLS
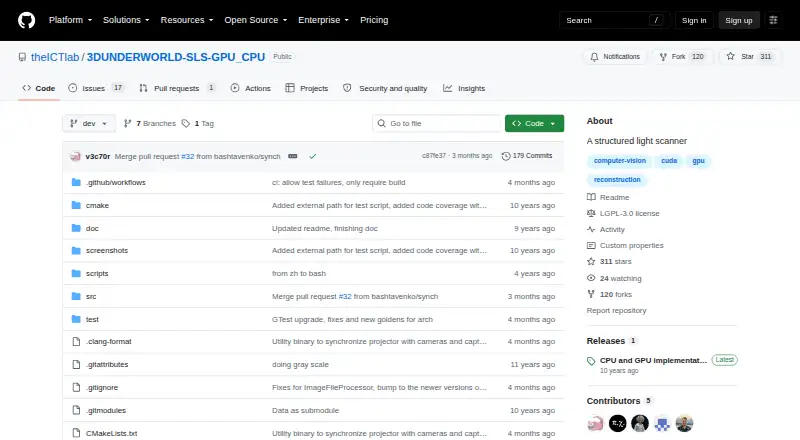
What 3DUNDERWORLD-SLS is
3DUNDERWORLD-SLS is Linux software for reconstructing point clouds from camera image sequences illuminated by patterned light. It is intended for structured-light scanning and provides reconstruction implementations for both CPU and GPU. The command-line demo accepts folders of camera images and calibration files, then can save results in PLY or OBJ format. Version 4.x uses two or more cameras and provides an interface programmers can extend to connect camera acquisition; acquisition itself is not implemented in the project.
The repository also includes libraries for integrating the reconstruction process into other projects, with CPU and GPU application examples. It provides demo binaries and sample data, alongside CMake instructions for building the binaries and libraries. The listed dependencies are OpenCV 2, CUDA 6.0 or later, and glm. When CUDA is detected, the default build creates CPU and GPU constructors; without CUDA, it creates only the CPU constructor. The repository includes the GNU Lesser General Public License version 3 with additional permissions. Users who publish work using the software are asked to cite specified publications. The project began in 2011 and is associated with a Montreal lab whose software page lists version 4.0 under active development.
Who it suits
3DUNDERWORLD-SLS suits researchers and developers building structured-light scanning workflows that reconstruct point clouds from camera images. It is also relevant to programmers integrating CPU or GPU reconstruction into another project and able to implement camera acquisition.
What it does well
- Free software for Linux.
- Reconstruction is implemented for both CPU and GPU.
- Exports reconstructed models in PLY or OBJ.
- Includes libraries and CPU and GPU application examples.
- Provides a camera interface programmers can extend.
What to know first
- Camera acquisition must be implemented by the user.
- Version 4.x requires two or more cameras.
- The build depends on OpenCV 2, CUDA 6.0 or later, and glm.
- It reconstructs point clouds, not meshes.
Limits
The project does not implement camera acquisition, so users need to provide a camera class. Without detected CUDA, the default build generates only the CPU constructor.
Getting started
- Open the project repository on GitHub.
- Use a Linux system.
- Install the listed dependencies: OpenCV 2, CUDA 6.0 or later, and glm.
- Use the included CMake script and instructions to build the binaries and libraries.
- Connect two or more cameras through an implemented camera class and provide image folders and calibration files to the demo.
Verdict
Choose 3DUNDERWORLD-SLS if you need free Linux software for structured-light point-cloud reconstruction and can build or adapt the scanning setup. Look elsewhere if you need camera acquisition included or mesh reconstruction.
Questions
Is 3DUNDERWORLD-SLS free?
Yes. The listed pricing model is free, with a free plan.
Which platform does it support?
Linux.
What does it export?
The command-line program can save reconstructed models in PLY or OBJ format.
Does it include an API or libraries for integration?
The project includes libraries intended for integration into other projects and CPU and GPU application examples. An API for 3DUNDERWORLD-SLS was included in OpenCV 3.1.
What does the build require?
The listed dependencies are OpenCV 2, CUDA 6.0 or later, and glm. If CUDA is detected, the default build creates CPU and GPU constructors; otherwise it creates only the CPU constructor.
What license does it use?
The repository includes the GNU Lesser General Public License version 3 with additional permissions.
Facts from 3DUNDERWORLD-SLS's own pages
- Build
- The repository includes demo binaries and data, and a CMake script to compile the binaries and libraries. · github.com, 7 Oct 2026
- Build requirements
- The listed dependencies are OpenCV 2, CUDA 6.0 or later, and glm. · github.com, 8 Oct 2026
- Camera acquisition
- Camera acquisition is not implemented, though the project provides interfaces for users to implement a camera class. · github.com, 7 Oct 2026
- Camera limitation
- Camera acquisition is not implemented; the project provides interfaces for users to implement a camera class. · github.com, 8 Oct 2026
- CPU and GPU
- The reconstruction process is implemented for both CPU and GPU, with CUDA-enabled builds generating both CPU and GPU executables when CUDA is detected. · github.com, 8 Oct 2026
- Data size
- The repository notes that its included example data makes the repository about 300 MB. · github.com, 7 Oct 2026
- Dependencies
- The listed dependencies are OpenCV 2, CUDA 6.0 or later, and glm. · github.com, 7 Oct 2026
- Download and build
- The repository includes demo binaries and data and provides CMake instructions to build the binaries and libraries. · github.com, 8 Oct 2026
- Founded
- 2011 · github.com, 28 Sept 2026
- GPU support
- If CUDA is detected, the default build creates CPU and GPU constructors; otherwise, it generates only the CPU constructor. · github.com, 7 Oct 2026
- Headquarters
- Montreal, Quebec · github.com, 28 Sept 2026
- Integration
- The project provides libraries intended for integration into other projects, with CPU and GPU application examples in the repository. · github.com, 8 Oct 2026
- Intended use
- The project's technical report describes the system as an open-source structured-light scanner for rapid geometry acquisition. · theictlab.org, 7 Oct 2026
- Intended users
- The lab describes its work as research and notes collaborations with industry and other external partners. · theictlab.org, 8 Oct 2026
- Library
- The project includes libraries intended for integration into other projects, with CPU and GPU application examples. · github.com, 7 Oct 2026
- License
- The GitHub repository identifies its license as LGPL-3.0. · github.com, 8 Oct 2026
- Output
- The command-line program can export reconstructed models in PLY or OBJ format. · github.com, 7 Oct 2026
- Outputs
- The demo accepts camera image folders and calibration files and can save output as PLY or OBJ. · github.com, 8 Oct 2026
- Processing
- Image processors use images, projector parameters, and camera calibration parameters to produce data that the reconstructor combines into a point cloud. · github.com, 8 Oct 2026
- Project status
- The lab's software page lists GPU-based structured-light scanning software V4.0 under “Under Active Development.” · theictlab.org, 8 Oct 2026
- Publication requirement
- The repository says users must cite specified publications in any resulting publication. · github.com, 8 Oct 2026
- Purpose
- The software reconstructs point clouds from series of images lit by patterned light. · github.com, 8 Oct 2026
- Research use
- The project asks users to cite the listed publications when using the software in resulting publications. · github.com, 7 Oct 2026
- Scanning setup
- Version 4.x requires two or more cameras and provides a generic camera interface that programmers can extend. · theictlab.org, 7 Oct 2026
Where 3DUNDERWORLD-SLS stands on Freedom251
- 3D Scanning Software#13 of 29